
外文翻译-步进电机外文翻译,中英对照
中文步进电机步进电机是将电脉冲信号转变为角位移或线位移的开环控制元步进电机件。
在非超载的情况下,电机的转速、停止的位置只取决于脉冲信号的频率和脉冲数,而不受负载变化的影响,当步进驱动器接收到一个脉冲信号,它就驱动步进电机按设定的方向转动一个固定的角度,称为“步距角”,它的旋转是以固定的角度一步一步运行的。
可以通过控制脉冲个数来控制角位移量,从而达到准确定位的目的;同时可以通过控制脉冲频率来控制电机转动的速度和加速度,从而达到调速的目的。
工作原理步进电机是一种感应电机,它的工作原理是利用电子电路,将直流电变成分时供电的,多相时序控制电流,用这种电流为步进电机供电,步进电机才能正常工作,驱动器就是为步进电机分时供电的,多相时序控制器虽然步进电机已被广泛地应用,但步进电机并不能象普通的直流电机,交流电机在常规下使用。
它必须由双环形脉冲信号、功率驱动电路等组成控制系统方可使用。
因此用好步进电机却非易事,它涉及到机械、电机、电子及计算机等许多专业知识。
步进电机作为执行元件,是机电一体化的关键产品之一, 广泛应用在各种自动化控制系统中。
随着微电子和计算机技术的发展,步进电机的需求量与日俱增,在各个国民经济领域都有应用。
分类现在比较常用的步进电机包括反应式步进电机(VR)、永磁式步进电机(PM)、混合式步进电机(HB)和单相式步进电机等。
永磁式步进电机永磁式步进电机一般为两相,转矩和体积较小,步进角一般为7.5度或15度;永磁式步进电动机输出力矩大,动态性能好,但步距角大。
反应式步进电机反应式步进电机一般为三相,可实现大转矩输出,步进角一般为1.5度,但噪声和振动都很大。
反应式步进电机的转子磁路由软磁材料制成,定子上有多相励磁绕组,利用磁导的变化产生转矩。
反应式步进电动机结构简单,生产成本低,步距角小;但动态性能差。
混合式步进电机混合式步进电动机综合了反应式、永磁式步进电动机两者的优点,它的步距角小,出力大,动态性能好,是目前性能最高的步进电动机。
它有时也称作永磁感应子式步进电动机。
它又分为两相和五相:两相步进角一般为1.8度而五相步进角一般为0.72度。
这种步进电机的应用最为广泛。
变频器对步进电机的节能改造三相步进电机专用变频器特点:■低频转矩输出180% ,低频运行特性良好■输出频率最大600Hz,可控制高速电机■全方位的侦测保护功能(过压、欠压、过载)瞬间停电再起动■加速、减速、动转中失速防止等保护功能■电机动态参数自动识别功能,保证系统的稳定性和精确性■高速停机时响应快■丰富灵活的输入、输出接口和控制方式,通用性强■采用SMT全贴装生产及三防漆处理工艺,产品稳定度高■全系列采用最新西门子IGBT功率器件,确保品质的高质量基本原理通常电机的转子为永磁体,当电流流过定子绕组时,定子绕组产生一矢量磁场。
该磁场会带动转子旋转一角度,使得转子的一对磁场方向与定子的磁场方向一致。
当定子的矢量磁场旋转一个角度。
转子也随着该磁场转一个角度。
每输入一个电脉冲,电动机转动一个角度前进一步。
它输出的角位移与输入的脉冲数成正比、转速与脉冲频率成正比。
改变绕组通电的顺序,电机就会反转。
所以可用控制脉冲数量、频率及电动机各相绕组的通电顺序来控制步进电机的转动。
反应式步进电机由于反应式步进电机工作原理比较简单。
下面先叙述三相反应式步进电机原理。
1、结构:电机转子均匀分布着很多小齿,定子齿有三个励磁绕阻,其几何轴线依次分别与转子齿轴线错开。
0、1/3て、2/3て,(相邻两转子齿轴线间的距离为齿距以て表示),即A与齿1相对齐,B与齿2向右错开1/3て,C与齿3向右错开2/3て,A'与齿5相对齐,(A'就是A,齿5就是齿1)下面是定转子的展开图:2、旋转:如A相通电,B,C相不通电时,由于磁场作用,齿1与A对齐,(转子不受任何力以下均同)。
如B相通电,A,C相不通电时,齿2应与B对齐,此时转子向右移过1/3て,此时齿3与C偏移为1/3て,齿4与A偏移(て-1/3て)=2/3て。
如C相通电,A,B相不通电,齿3应与C对齐,此时转子又向右移过1/3て,此时齿4与A偏移为1/3て对齐。
如A相通电,B,C相不通电,齿4与A对齐,转子又向右移过1/3て这样经过A、B、C、A分别通电状态,齿4(即齿1前一齿)移到A相,电机转子向右转过一个齿距,如果不断地按A,B,C,A……通电,电机就每步(每脉冲)1/3て,向右旋转。
如按A,C,B,A……通电,电机就反转。
由此可见:电机的位置和速度由导电次数(脉冲数)和频率成一一对应关系。
而方向由导电顺序决定。
不过,出于对力矩、平稳、噪音及减少角度等方面考虑。
往往采用A-AB-B-BC-C-CA-A这种导电状态,这样将原来每步1/3て改变为1/6て。
甚至于通过二相电流不同的组合,使其1/3て变为1/12て,1/24て,这就是电机细分驱动的基本理论依据。
不难推出:电机定子上有m相励磁绕阻,其轴线分别与转子齿轴线偏移1/m,2/m……(m-1)/m,1。
并且导电按一定的相序电机就能正反转被控制——这是旋转的物理条件。
只要符合这一条件我们理论上可以制造任何相的步进电机,出于成本等多方面考虑,市场上一般以二、三、四、五相为多。
3、力矩:电机一旦通电,在定转子间将产生磁场(磁通量Ф)当转子与定子错开一定角度产生力F与(dФ/dθ)成正比S 其磁通量Ф=Br*S Br为磁密,S为导磁面积F与L*D*Br成正比L为铁芯有效长度,D为转子直径Br=N·I/R N·I为励磁绕阻安匝数(电流乘匝数)R为磁阻。
力矩=力*半径力矩与电机有效体积*安匝数*磁密成正比(只考虑线性状态)因此,电机有效体积越大,励磁安匝数越大,定转子间气隙越小,电机力矩越大,反之亦然。
感应子式步进电机1、特点:感应子式与传统的反应式相比,结构上转子加有永磁体,以提供软磁材料的工作点,而定子激磁只需提供变化的磁场而不必提供磁材料工作点的耗能,因此该电机效率高,电流小,发热低。
因永磁体的存在,该电机具有较强的反电势,其自身阻尼作用比较好,使其在运转过程中比较平稳、噪音低、低频振动小。
感应子式某种程度上可以看作是低速同步的电机。
一个四相电机可以作四相运行,也可以作二相运行。
(必须采用双极电压驱动),而反应式电机则不能如此。
例如:四相,八相运行(A-AB-B-BC-C-CD-D-DA-A)完全可以采用二相八拍运行方式.不难发现其条件为C=,D=. 一个二相电机的内部绕组与四相电机完全一致,小功率电机一般直接接为二相,而功率大一点的电机,为了方便使用,灵活改变电机的动态特点,往往将其外部接线为八根引线(四相),这样使用时,既可以作四相电机使用,可以作二相电机绕组串联或并联使用。
2、分类感应子式电机以相数可分为:二相电机、三相电机、四相电机、五相电机等。
以机座号(电机外径)可分为:42BYG(BYG为感应子式步进电机代号)、57BYG、86BYG、110BYG、(国际标准),而像70BYG、90BYG、130BYG等均为国内标准。
3、步进电机的静态指标术语相数:产生不同对极N、S磁场的激磁线圈对数。
常用m表示。
拍数:完成一个磁场周期性变化所需脉冲数或导电状态用n表示,或指电机转过一个齿距角所需脉冲数,以四相电机为例,有四相四拍运行方式即AB-BC-CD-DA-AB,四相八拍运行方式即A-AB-B-BC-C-CD-D-DA-A. 步距角:对应一个脉冲信号,电机转子转过的角位移用θ表示。
θ=360度(转子齿数J*运行拍数),以常规二、四相,转子齿为50齿电机为例。
四拍运行时步距角为θ=360度/(50*4)=1.8度(俗称整步),八拍运行时步距角为θ=360度/(50*8)=0.9度(俗称半步)。
定位转矩:电机在不通电状态下,电机转子自身的锁定力矩(由磁场齿形的谐波以及机械误差造成的)静转矩:电机在额定静态电作用下,电机不作旋转运动时,电机转轴的锁定力矩。
此力矩是衡量电机体积(几何尺寸)的标准,与驱动电压及驱动电源等无关。
虽然静转矩与电磁激磁安匝数成正比,与定齿转子间的气隙有关,但过分采用减小气隙,增加激磁安匝来提高静力矩是不可取的,这样会造成电机的发热及机械噪音。
4、动态指标及术语:1、步距角精度:步进电机每转过一个步距角的实际值与理论值的误差。
用百分比表示:误差/步距角*100%。
不同运行拍数其值不同,四拍运行时应在5%之内,八拍运行时应在15%以内。
2、失步:电机运转时运转的步数,不等于理论上的步数。
称之为失步。
3、失调角:转子齿轴线偏移定子齿轴线的角度,电机运转必存在失调角,由失调角产生的误差,采用细分驱动是不能解决的。
4、最大空载起动频率:电机在某种驱动形式、电压及额定电流下,在不加负载的情况下,能够直接起动的最大频率。
5、最大空载的运行频率:电机在某种驱动形式,电压及额定电流下,电机不带负载的最高转速频率。
6、运行矩频特性:电机在某种测试条件下测得运行中输出力矩与频率关系的曲线称为运行矩频特性,这是电机诸多动态曲线中最重要的,也是电机选择的根本依据。
如下图所示:其它特性还有惯频特性、起动频率特性等。
电机一旦选定,电机的静力矩确定,而动态力矩却不然,电机的动态力矩取决于电机运行时的平均电流(而非静态电流),平均电流越大,电机输出力矩越大,即电机的频率特性越硬。
如下图所示:其中,曲线3电流最大、或电压最高;曲线1电流最小、或电压最低,曲线与负载的交点为负载的最大速度点。
要使平均电流大,尽可能提高驱动电压,使采用小电感大电流的电机。
7、电机的共振点:步进电机均有固定的共振区域,二、四相感应子式的共振区一般在180-250pps之间(步距角1.8度)或在400pps左右(步距角为0.9度),电机驱动电压越高,电机电流越大,负载越轻,电机体积越小,则共振区向上偏移,反之亦然,为使电机输出电矩大,不失步和整个系统的噪音降低,一般工作点均应偏移共振区较多。
8、电机正反转控制:当电机绕组通电时序为AB-BC-CD-DA或()时为正转,通电时序为DA-CD-BC-AB或()时为反转。
步进电机的一些基本参数电机固有步距角它表示控制系统每发一个步进脉冲信号,电机所转动的角度。
电机出厂时给出了一个步距角的值,如86BYG250A型电机给出的值为0.9°/1.8°(表示半步工作时为0.9°、整步工作时为1.8°),这个步距角可以称之为…电机固有步距角‟,它不一定是电机实际工作时的真正步距角,真正的步距角和驱动器有关。
通常步进电机步距角β的一般计算按下式计算。
β=360°/(Z·m·K)式中β―步进电机的步距角;Z―转子齿数;m―步进电动机的相数;K―控制系数,是拍数与相数的比例系数步进电机的相数是指电机内部的线圈组数,目前常用的有二相、三相、四相、五相步进电机。
步进电机-英文资料及翻译(Stepping Motor Types)
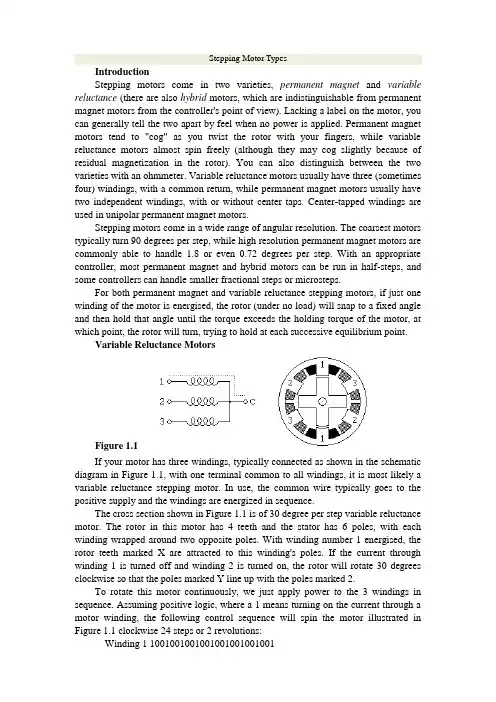
Stepping Motor TypesIntroductionStepping motors come in two varieties, permanent magnet and variable reluctance (there are also hybrid motors, which are indistinguishable from permanent magnet motors from the controller's point of view). Lacking a label on the motor, you can generally tell the two apart by feel when no power is applied. Permanent magnet motors tend to "cog" as you twist the rotor with your fingers, while variable reluctance motors almost spin freely (although they may cog slightly because of residual magnetization in the rotor). You can also distinguish between the two varieties with an ohmmeter. Variable reluctance motors usually have three (sometimes four) windings, with a common return, while permanent magnet motors usually have two independent windings, with or without center taps. Center-tapped windings are used in unipolar permanent magnet motors.Stepping motors come in a wide range of angular resolution. The coarsest motors typically turn 90 degrees per step, while high resolution permanent magnet motors are commonly able to handle 1.8 or even 0.72 degrees per step. With an appropriate controller, most permanent magnet and hybrid motors can be run in half-steps, and some controllers can handle smaller fractional steps or microsteps.For both permanent magnet and variable reluctance stepping motors, if just one winding of the motor is energised, the rotor (under no load) will snap to a fixed angle and then hold that angle until the torque exceeds the holding torque of the motor, at which point, the rotor will turn, trying to hold at each successive equilibrium point.Variable Reluctance MotorsFigure 1.1If your motor has three windings, typically connected as shown in the schematic diagram in Figure 1.1, with one terminal common to all windings, it is most likely a variable reluctance stepping motor. In use, the common wire typically goes to the positive supply and the windings are energized in sequence.The cross section shown in Figure 1.1 is of 30 degree per step variable reluctance motor. The rotor in this motor has 4 teeth and the stator has 6 poles, with each winding wrapped around two opposite poles. With winding number 1 energised, the rotor teeth marked X are attracted to this winding's poles. If the current through winding 1 is turned off and winding 2 is turned on, the rotor will rotate 30 degrees clockwise so that the poles marked Y line up with the poles marked 2.To rotate this motor continuously, we just apply power to the 3 windings in sequence. Assuming positive logic, where a 1 means turning on the current through a motor winding, the following control sequence will spin the motor illustrated in Figure 1.1 clockwise 24 steps or 2 revolutions:Winding 1 1001001001001001001001001Winding 2 0100100100100100100100100Winding 3 0010010010010010010010010 time --->The section of this tutorial on Mid-Level Control provides details on methods for generating such sequences of control signals, while the section on Control Circuits discusses the power switching circuitry needed to drive the motor windings from such control sequences.There are also variable reluctance stepping motors with 4 and 5 windings, requiring 5 or 6 wires. The principle for driving these motors is the same as that for the three winding variety, but it becomes important to work out the correct order to energise the windings to make the motor step nicely.The motor geometry illustrated in Figure 1.1, giving 30 degrees per step, uses the fewest number of rotor teeth and stator poles that performs satisfactorily. Using more motor poles and more rotor teeth allows construction of motors with smaller step angle. Toothed faces on each pole and a correspondingly finely toothed rotor allows for step angles as small as a few degrees.Unipolar MotorsFigure 1.2Unipolar stepping motors, both Permanent magnet and hybrid stepping motors with 5 or 6 wires are usually wired as shown in the schematic in Figure 1.2, with a center tap on each of two windings. In use, the center taps of the windings are typically wired to the positive supply, and the two ends of each winding are alternately grounded to reverse the direction of the field provided by that winding.The motor cross section shown in Figure 1.2 is of a 30 degree per step permanent magnet or hybrid motor -- the difference between these two motor types is not relevant at this level of abstraction. Motor winding number 1 is distributed between the top and bottom stator pole, while motor winding number 2 is distributed between the left and right motor poles. The rotor is a permanent magnet with 6 poles, 3 south and 3 north, arranged around its circumfrence.For higher angular resolutions, the rotor must have proportionally more poles. The 30 degree per step motor in the figure is one of the most common permanent magnet motor designs, although 15 and 7.5 degree per step motors are widely available. Permanent magnet motors with resolutions as good as 1.8 degrees per step are made, and hybrid motors are routinely built with 3.6 and 1.8 degrees per step, with resolutions as fine as 0.72 degrees per step available.As shown in the figure, the current flowing from the center tap of winding 1 to terminal a causes the top stator pole to be a north pole while the bottom stator pole is a south pole. This attracts the rotor into the position shown. If the power to winding 1 is removed and winding 2 is energised, the rotor will turn 30 degrees, or one step.To rotate the motor continuously, we just apply power to the two windings in sequence. Assuming positive logic, where a 1 means turning on the current through a motor winding, the following two control sequences will spin the motor illustrated in Figure 1.2 clockwise 24 steps or 2 revolutions:Winding 1a 1000100010001000100010001Winding 1b 0010001000100010001000100Winding 2a 0100010001000100010001000Winding 2b 0001000100010001000100010 time --->Winding 1a 1100110011001100110011001Winding 1b 0011001100110011001100110Winding 2a 0110011001100110011001100Winding 2b 1001100110011001100110011 time --->Note that the two halves of each winding are never energized at the same time. Both sequences shown above will rotate a permanent magnet one step at a time. The top sequence only powers one winding at a time, as illustrated in the figure above; thus, it uses less power. The bottom sequence involves powering two windings at a time and generally produces a torque about 1.4 times greater than the top sequence while using twice as much power.The section of this tutorial on Mid-Level Control provides details on methods for generating such sequences of control signals, while the section on Control Circuits discusses the power switching circuitry needed to drive the motor windings from such control sequences.The step positions produced by the two sequences above are not the same; as a result, combining the two sequences allows half stepping, with the motor stopping alternately at the positions indicated by one or the other sequence. The combined sequence is as follows:Winding 1a 11000001110000011100000111Winding 1b 00011100000111000001110000Winding 2a 01110000011100000111000001Winding 2b 00000111000001110000011100time --->Bipolar MotorsFigure 1.3Bipolar permanent magnet and hybrid motors are constructed with exactly the same mechanism as is used on unipolar motors, but the two windings are wired more simply, with no center taps. Thus, the motor itself is simpler but the drive circuitry needed to reverse the polarity of each pair of motor poles is more complex. The schematic in Figure 1.3 shows how such a motor is wired, while the motor cross section shown here is exactly the same as the cross section shown in Figure 1.2.The drive circuitry for such a motor requires an H-bridge control circuit for each winding; these are discussed in more detail in the section on Control Circuits. Briefly, an H-bridge allows the polarity of the power applied to each end of each winding to be controlled independently. The control sequences for single stepping such a motor are shown below, using + and - symbols to indicate the polarity of the power applied to each motor terminal:Terminal 1a +---+---+---+--- ++--++--++--++--Terminal 1b --+---+---+---+- --++--++--++--++Terminal 2a -+---+---+---+-- -++--++--++--++-Terminal 2b ---+---+---+---+ +--++--++--++--+ time --->Note that these sequences are identical to those for a unipolar permanent magnet motor, at an abstract level, and that above the level of the H-bridge power switching electronics, the control systems for the two types of motor can be identical.Note that many full H-bridge driver chips have one control input to enable the output and another to control the direction. Given two such bridge chips, one per winding, the following control sequences will spin the motor identically to the control sequences given above:Enable 1 1010101010101010 1111111111111111Direction 1 1x0x1x0x1x0x1x0x 1100110011001100Enable 2 0101010101010101 1111111111111111Direction 2 x1x0x1x0x1x0x1x0 0110011001100110 time --->To distinguish a bipolar permanent magnet motor from other 4 wire motors, measure the resistances between the different terminals. It is worth noting that some permanent magnet stepping motors have 4 independent windings, organized as two sets of two. Within each set, if the two windings are wired in series, the result can be used as a high voltage bipolar motor. If they are wired in parallel, the result can be used as a low voltage bipolar motor. If they are wired in series with a center tap, the result can be used as a low voltage unipolar motor. Bifilar MotorsBifilar windings on a stepping motor are applied to the same rotor and stator geometry as a bipolar motor, but instead of winding each coil in the stator with a single wire, two wires are wound in parallel with each other. As a result, the motor has 8 wires, not four.In practice, motors with bifilar windings are always powered as either unipolar or bipolar motors. Figure 1.4 shows the alternative connections to the windings of such a motor.Figure 1.4To use a bifilar motor as a unipolar motor, the two wires of each winding are connected in series and the point of connection is used as a center-tap. Winding 1 in Figure 1.4 is shown connected this way.To use a bifilar motor as a bipolar motor, the two wires of each winding are connected either in parallel or in series. Winding 2 in Figure 1.4 is shown with a parallel connection; this allows low voltage high-current operation. Winding 1 in Figure 1.4 is shown with a series connection; if the center tap is ignored, this allows operation at a higher voltage and lower current than would be used with the windings in parallel.It should be noted that essentially all 6-wire motors sold for bipolar use are actually wound using bifilar windings, so that the external connection that serves as a center tap is actually connected as shown for winding 1 in Figure 1.4. Naturally, therefore, any unipolar motor may be used as a bipolar motor at twice the rated voltage and half the rated current as is given on the nameplate.The question of the correct operating voltage for a bipolar motor run as a unipolar motor, or for a bifilar motor with the motor windings in series is not as trivial as it might first appear. There are three issues: The current carrying capacity of the wire, cooling the motor, and avoiding driving the motor's magnetic circuits into saturation. Thermal considerations suggest that, if the windings are wired in series, the voltage should only be raised by the square root of 2. The magnetic field in the motor depends on the number of ampere turns; when the two half-windings are run in series, the number of turns is doubled, but because a well-designed motor has magnetic circuits that are close to saturation when the motor is run at its rated voltage and current, increasing the number of ampere-turns does not make the field any stronger. Therefore, when a motor is run with the two half-windings in series, the current should be halved in order to avoid saturation; or, in other words, the voltage across the motor winding should be the same as it was.For those who salvage old motors, finding an 8-wire motor poses a challenge! Which of the 8 wires is which? It is not hard to figure this out using an ohm meter, an AC volt meter, and a low voltage AC source. First, use the ohm meter to identify the motor leads that are connected to each other through the motor windings. Then, connect a low-voltage AC source to one of these windings. The AC voltage should be below the advertised operating voltage of the motor; voltages under 1 volt are recommended. The geometry of the magnetic circuits of the motor guarantees that the two wires of a bifilar winding will be strongly coupled for AC signals, while there should be almost no coupling to the other two wires. Therefore, probing with an AC volt meter should disclose which of the other three windings is paired to the winding under power. Multiphase MotorsFigure 1.5A less common class of permanent magnet or hybrid stepping motor is wired with all windings of the motor in a cyclic series, with one tap between each pair ofwindings in the cycle, or with only one end of each motor winding exposed while the other ends of each winding are tied together to an inaccessible internal connection. In the context of 3-phase motors, these configurations would be described as Delta and Y configurations, but they are also used with 5-phase motors, as illustrated in Figure 1.5. Some multiphase motors expose all ends of all motor windings, leaving it to the user to decide between the Delta and Y configurations, or alternatively, allowing each winding to be driven independently.Control of either one of these multiphase motors in either the Delta or Y configuration requires 1/2 of an H-bridge for each motor terminal. It is noteworthy that 5-phase motors have the potential of delivering more torque from a given package size because all or all but one of the motor windings are energised at every point in the drive cycle. Some 5-phase motors have high resolutions on the order of 0.72 degrees per step (500 steps per revolution).Many automotive alternators are built using a 3-phase hybrid geometry with either a permanent magnet rotor or an electromagnet rotor powered through a pair of slip-rings. These have been successfully used as stepping motors in some heavy duty industrial applications; step angles of 10 degrees per step have been reported.With a 5-phase motor, there are 10 steps per repeat in the stepping cycle, as shown below:Terminal 1 +++-----+++++-----++Terminal 2 --+++++-----+++++---Terminal 3 +-----+++++-----++++Terminal 4 +++++-----+++++-----Terminal 5 ----+++++-----+++++-time --->With a 3-phase motor, there are 6 steps per repeat in the stepping cycle, as shown below:Terminal 1 +++---+++---Terminal 2 --+++---+++-Terminal 3 +---+++---++time --->Here, as in the bipolar case, each terminal is shown as being either connected to the positive or negative bus of the motor power system. Note that, at each step, only one terminal changes polarity. This change removes the power from one winding attached to that terminal (because both terminals of the winding in question are of the same polarity) and applies power to one winding that was previously idle. Given the motor geometry suggested by Figure 1.5, this control sequence will drive the motor through two revolutions.To distinguish a 5-phase motor from other motors with 5 leads, note that, if the resistance between two consecutive terminals of the 5-phase motor is R, the resistance between non-consecutive terminals will be 1.5R.Note that some 5-phase motors have 5 separate motor windings, with a total of 10 leads. These can be connected in the star configuration shown above, using 5 half-bridge driver circuits, or each winding can be driven by its own full-bridge. While the theoretical component count of half-bridge drivers is lower, the availability of integrated full-bridge chips may make the latter approach preferable.步进电机•介绍•变磁阻电机•单极电机•双极电机•单一电机•多相电机介绍步进电动机分成两类、永磁和变磁阻(也有混合电机、永磁电机与从控制器的观点)。
电机专业术语中英文对照
电机 electric engine; electric machine; electric (al) motor电机参数 parameter of electric machine电机槽宽 tooth ratio电机槽内导体 electric machine slot-conductor电机常数 constant of the machine电机厂 motormaker电机车 haulage motor电机车架空线保护 trolley wire guard电机车运输 electric(al) haulage电机传动辊 motorised roll电机传动轴 motor transmission shaft电机磁场 motor-field电机的电气线端 electric terminals of a machine电机的规格 rating of machine电机的输入功率 power input to a machine电机的铁间空隙 entrefer电机底座 motor base电机电刷 motor brush电机调整器 regulator generator电机定子铁芯自动焊接机 dynamo stator core automatic welder电机端部磁场 end-region magnetic field of electrical machine电机短路测试仪 electric motor short circuit test instrument电机放大器 amplidyne generator; motor amplifier; rotating amplifier 电机放大器控制部件 amplidyne control unit电机放大器伺服系统 amplidyne servomechanism电机放大伺服机构 amplidyne servomechanism电机钢 dynamo steel电机钢板 dynamo steel sheet电机工程 electric engineering电机工程师 electrical engineer电机功率 power of motor电机规格 rating of machine电机硅钢片 dynamo sheet电机黄铜合金 motor brass alloy电机减速机 motor reducer; motor reducing gear电机壳 motor casing; motor enclosure电机控制 electric machine control电机控制器 machine controller电机偏心率 motor eccentricity电机起动器 motor starter电机青铜 dynamo bronze电机驱动 motor drive电机驱动的 motor-driven电机驱动开关 motor driven switch电机驱动种子清选机 motor-driven seed cleaner电机绕组 machine winding电机设计 electric machine design电机室 motor room电机输送 motor transport电机数量 number of motors电机损耗 loss of machine电机碳刷 carbon brush for electric machine; motor carbon电机效率 electric efficiency; electrical efficiency电机械加工 electromechanical working电机械模拟 electromechanical analogy电机学 electromechanics电机用薄钢片 dynamo sheet steel电机用硅钢片 dynamo steel sheet电机用油 motor oil电机油 dynamo oil; electric engine oil电机运行特性 electric machine operating characteristic电机制造业 electric manufacturing电机轴 motor shaft电机轴承 motor bearings电机转子试验装置 motor rotor tester电机转子压铸机 die-casting machine for motor rotor电机自动继电器 motor automatic relay电机座 motor cabinet电机座位 motor cavity3-phase slip-ring induction motor 三相滑环式感应电动机3-phase squirrel cage induction motor 三相鼠笼式感应电动机battery-operated motor cycle (玩具) 电动摩托车bearing of motor 电动机轴承bin drive motor 分页格驱动电机biphase motor 两相电动机bisynchronous motor 双倍同步速度电动机blower motor 鼓风电动机; 鼓风机用马达boost motor 助推器; 加速器Boucherot (squirrel-cage) motor 双鼠笼式电动机box-frame motor 箱形机座电动机; 框形电动机brake motor 制动电动机brush and slotless motor 无电刷槽电动机brush motor 换向器电动机; 整流式电动机brush-shifting motor 移刷型电动机built-in motor drive 单独电机传动; 单独内装电机传动built-in motor 机内电动机cage motor 鼠笼式电动机cam-type axial piston motor 斜盘式轴向柱塞电动机canned motor pump 密封电动泵; 密封式电动泵; 屏蔽泵canned motor 封闭电动机; 密封式发动机capacitive motor 电容电动机capacitor induction motor 电容电动机capacitor motor 电容起动电动机; 电容器起动电动机; 电容式单相电动机; 电容式电动机capacitor split-phase motor 电容分相式电动机capacitor start and run motor 电容起动行驶式电动机capacitor start motor 电容起动电动机capacitor start-run motor 固定分相电容器式电动机capacitor-start motor 电容器起动电动机; 电容式启动电动机capacitor-start-and-run motor 电容式启动和运转的电动机capstan motor 主导电动机; 主动轮电动机cascade motor 级联电动机cascade motors 级联电动机组ceiling-fan motor 吊扇电机cell motor 电池电动机centre drvie motor mower 中央驱动动力割草机ceramic permanent-magnet motor 陶瓷永磁电动机; 铁淦氧永磁电动机chain-drive motorcycle 链动机器脚踏车chain-type side-rake for motormower 动力割草机的链指式侧向搂草器change speed motor 分级调速式电动机change-speed motor 变速电动机charge motor 充电马达; 充电用电动机chopper motor 斩波器供电电动机; 断路电动机Class I Motor Carrier 一级汽车运输公司clock motor 计时电动机; 电钟用电动机close-ratio two-speed motor 近比率双速电动机closing motor 密闭电动机clutch motor 带离合器电动机coastal motor boat 海岸汽船coller for motor 电动机冷却器combustion motor 内燃机commercial motor 商用电动机common pumpl motor base 泵与电动机的共用底座commutating pole motor 换向极电动机commutator induction motor 换向器感应电动机commutator motor 换向器式电动机; 整流式电动机; 整流子式电动机commutator variable speed motor 换向器变速电动机compass torque motor 罗盘矫正电动机compensated commutator motor 补偿整流电动机compensated induction motor 补偿感应电动机; 补偿式感应电动机compensated motor 补偿电动机compensated repulsion motor 补偿感应推斥电动机; 补偿式推斥电动机; 补偿推斥电动机; 补偿推斥式电动机compensated series motor 补偿串激式电动机; 补偿串励电动机complete motor type 配带电机型号compound motor 复励电动机compound-wound motor 复激电动机; 复励电动机compressed air motor 气动电动机concatenated motor 级联电动机; 链系电动机; 串级电动机concatenation motor 链系电动机; 串级电动机condenser motor 电容式电动机condenser run motor 电容起动电动机condenser shunt type induction motor 电容分相式感应电动机condenser start motor 电容起动电动机condenser-start induction motor 电容起动感应电动机connector motor magnet 回转电磁铁consequent-poles motor 变极式双速电动机; 交替磁极式电动机constant current motor 定流电动机constant displacement motor 定量马达constant field commutator motor 定激励整流式电动机constant power motor 恒定功率电动机constant pressure motor 等压内燃机constant speed motor 等速电动机; 恒速电动机; 定速电动机constant torque asynchronous motor 恒力矩异步电动机constant voltage motor generator 恒压电动机发电机constant voltage motor 恒压电动机; 定电压电动机constant-current motor 恒流电动机constant-speed motor 等速马达constant-voltage motor 恒定电压电动机continuously rated motor 连续额定运行电动机continuous-time-rated motor 连续运行电动机converter-fed motor 换流器供电电动机coolant pump motor 冷却液泵电动机cooled motor 冷却式发动机crane motor 吊车电动机crawler-type motor grader 履带式自动平地机crescent gear motor 内啮合齿轮马达cross feed motor 交叉馈电式电动机cumulative compound motor 积复激电动机cup motor 杯形电机current-displacement motor 深槽电动机; 深槽感应电动机cutter motor 截煤机电动机cycloid gear hydraulic motor 摆线齿轮油液压马达cycloidal gear reducing motor 摆线齿轮减速电动机cycloidal needle wheel type motor 摆线针轮电动机DC electronic motor 离子式直流电动机DC series motor 串激直流电动机dead motor 关闭的电动机decompounded motor 差复励电动机decussation motoria 运动交叉deep-bar motor 深槽鼠笼式电动机deep-slot induction motor 深槽感应电动机deep-slot motor 深槽感应电动机deep-slot squirrel cage motor 深槽鼠笼式电动机definite-purpose motor 专用电动机deluge proof motor 防水电动机Denison motor 丹尼森液压电动机; 轴向回转柱塞式液压电动机Deri motor 德里电动机Deri repulsion motor 德里推斥电动机despun motor 反旋转电动机; 反自转电动机diaphragm motor 膜片阀控制电动机; 光阑驱动电动机die-casting machine for motor rotor 电机转子压铸机diesel motor roller 柴油碾压机; 柴油压路机diesel motor 狄塞尔发动机differential compound motor 差复激电动机; 差复励电动机; 差复励电视机; 差复绕电动机; 差绕复激电动机differential motor 差绕电动机differential selsyn motor 差动自动同步电机differential shunt motor 差并励电动机differential wound motor 差励电动机differential-field motor 他激差绕直流电动机differential-field series motor 串激差绕直流电动机differentially-compound wound motor 差复激电动机differentially-wound motor 差绕电动机direct motor drive 电动机直接传动direct motor driven 单电动机传动的direct-connected motor 直连电动机direct-coupling motor converter 连轴电动换流机direct-current motor control 电动机电子控制direct-motor-driven 单电动机传动disabled motor switch 电动机故障断路器dither motor 高频振动电动机; 高频振动电机; 高频振动用电动机double armature motor 双电枢电动机double commutator motor 双整流子电动机; 双换向器电动机double motor 双电动机double squirrelcage motor 双鼠笼电动机double-casing motor 双层机壳式电机double-fed repulsion motor 双馈推斥电动机double-reduction motor 两级减速电动机double-unit motor 双电动机机组drag-cup induction motor 空心转子感应电动机drag-cup motor 拖杯式电动机; 托杯形电动机drag-cup type rotor motor 空心转子电动机drill-motor rotor vane 钻孔转子叶片drip-proof motor 防滴式电动机drip-proof type induction motor 防滴式感应电动机drive motor 传动马达driver motor 主驱动电动机driving shaft motor 传动轴电机drop-proof type motor 防滴水式电动机drum motor 鼓形电动机dual-capacitor motor 双电容器式电动机dual-frequency motor 双频率电动机dual-thrust motor 双推力发动机duocentric motor 同心双转子电动机duplex power feed type A.C. commutator motor 并联馈电整流式交流电动机dust-tight type motor 防尘式电动机dynamoelectric motor 旋转换流机eddy currents in attraction type motor 吸引型电动机中的涡流eddy-current motor 涡流电动机either-rotation motor 双向电机electric (al) motor 电机electric hoist with creep lifting motor 变速电葫芦electric motor car 电动车; 电动机车electric motor coach 电动客车electric motor drive 电动机传动electric motor driven butter churn 电动乳脂制作器electric motor for rolling way 辊道电动机electric motor generator 电动发电机electric motor movie camera 电动式活动摄影机electric motor oil 电动机油electric motor saw 电锯; 电力锯electric motor short circuit test instrument 电机短路测试仪electric motor signal mechanism 电动臂板信号机构electric motor truck 电气载重车electric motor 电动机electric motor-drawn channel scraper 电动粪槽刮铲electric motordriven point mechanism 电动转辙机构electric motor-operated fixed crane 固定式电动起重机electric pulse motor 电脉冲电动机electric starter motor 电力起动机electric vehicle motor 牵引电动机electric wiper motor 刮水器电动机electrical motor 电动机electrically operated motor car 电动车electro-hydraulic servo motor 电动液压伺服电动机electrohydraulic stepping motor 电液步进马达electromagnetic speed-adjustable motor 电磁调速电动机electromagnetic variable-speed motor 电磁调速电动机electro-motor 电动马达electronic motor control 电动机电子控制electronic motor controller 电子电动机控制器electropneumatic point motor 电动气动转辙机electropneumatic signal motor 电动气动信号机electrostatic motor 静电电动机; 静电电动机elevating motor 升降电动机elevation drive motor 仰角传动电动机; 仰角驱动电动机enclosed motor 密封式电动机; 封闭电动机; 封闭式电动机; 封闭型电动机enclosed type induction motor 封闭式感应电动机enclosed type motor 封闭式电动机enclosed ventilated motor 封闭通风式电动机engine cranking motor 发动机起动马达Enor motor 埃诺罗式叶片液压马达E-P signal motor 电动气动信号机epicycle motor 行星减速电动机erection torque motor 竖起力矩电动机; 架设转矩电动机exciter motor-generator 励磁电动发电机expiratory motor neuron 呼气运动神经元explosion motor 爆燃式发动机explosion-proof motor 防爆马达; 防爆型电机explosion-proof type induction motor 防爆式感应电动机explosion-proof ventilated synchronous motor 防爆通风型同步电动机explosive motor 内燃发动机external concrete vibrators with motor 带电动机的混凝土振动器externally reversible motor 双向启动可逆电动机external-rotor motor 外转子式电动机face-type motor 凸缘型电动机fan motor 风扇电动机; 风扇马达fan-cooled motor 全封密风冷式电动机farm motor 农用电动机feed motor 进给电动机Ferrari s motor 费拉里电动机field-control motor 磁场可控式电动机; 可调磁场型电动机fixed brush type polyphase series motor 固定电刷式多相串激电动机fixed displacement motor 定量马达fixed-displacement motor 定容量马达flame-proof 3-phase induction motor 防爆型三相感应电动机flame-proof electric motor 防爆电动机flame-proof motor 防爆式电动机flange motor 凸缘底座电动机; 凸缘型电动机flanged motor 凸缘电动机flange-mounted motor 凸缘型电动机flange-type motor 凸缘型电动机; 法兰式电动机flea-size motor 超小型电动机fluid motor 液力发动机; 液压马达fluid power motor 液压发动机fluid pressure motor 液压电动机fluid servo-motor 液压伺服马达fluidic stepping motor 射流式步进电动机fluid-power motor 液力电动机; 液力马达follower motor 随动电动机foot engine with electric motor 牙科脚踏电动二用钻机foot-mounted motor 底座安装型电动机; 落地安装型电动机force motor 执行电动机forced-ventilated motor 强制通风式电动机form-wound motorette 模绕线圈试验装置foundation bolt for motor 电动机地脚螺栓four-phase stepper motor 四相步进电动机four-pole motor 四极电动机four-stroke motor 四冲程发动机four-wheel motor vehicle 四轮机动车辆fractional electric motor 小功率电动机; 分马力电动机fractional horse power motor 分数马力电动机fractional horsepower motor 分马力电动机fractional horse-power motor 分数功率电动机fractional HP light metal induction motors 铝合金壳分马力感应电动机fractional-horsepower asynchronous motor 分马力异步电动机fractional-horsepower motor 低功率电动机fractional-horse-power motor 小马力电动机frame suspended motor 底架悬挂电动机; 底座悬挂型电动机frost-proof motor 耐寒式电动机full voltage starting motor 全电压起动电动机fully-flameproof motor 全防爆型电动机gas for motor fuel 气态发动机燃料; 动力煤气gas motor 煤气发动机; 煤气机gasoline motor car 汽油车gasoline motor 汽油发动机gas-pressurized rocket motor 气压式液体火箭发动机gate motor 栏木电动机gear head motor 齿轮减速电动机gear motor for screw conveyer 螺旋输送器减速电动机gear motor 齿轮电动机; 齿轮马达gear(ed) motor 减速电动机geared motor 齿轮传动电动机; 齿轮传动马达; 齿轮电动机; 带变速齿轮箱的电动机;带减速齿轮的电动机geared-down motor 齿轮减速发动机gear-type hydraulic motor 齿轮式液压马达gear-type motor 齿轮液压电动机gear-within-gear motor 内啮合齿轮马达general-purpose motor 通用电动机generator-motor set 发电机电动机组gimbal servo motor 万向伺服电动机gimbaled motor 悬挂式电动机gimbaling rocket motor 万向架支座火箭发动机glass reinforced plastic motor lifeboat 玻璃钢机动救生艇governor motor 调节马达; 调速电动机; 调速器电动机; 调速器用电动机; 调整机用电动机graduation of the motor currents 电动机电流级加法gramophone motor 唱机电动机grinding head motor for woodworking 木工专用磨头电动机grinding head motor 磨头电动机grinding wheel drive motor 砂轮电机gunmetals motor carriage 机械化炮车gyro motor 陀螺马达hand motor 手电动机harmonic motor 谐波电动机haulage motor 电机车head motor 头部发动机heat-pipe motor 热管冷却电动机heat-resistant motor 耐热电动机; 高温电动机heavy motor truck 重型载货汽车Hele-Shaw motor 径向活塞式液压电动机; 径向活塞式液压电动机hermetic motor 密封式电动机; 密封式电动机; 密封型电动机hermetically sealed motor 密封式电动机hermetically-sealed motor 密封型电动机heteropolar D.C. linear motor 多极直流直线电动机high capacity motor 高功率电动机high frequency motor generator 高频电动发电机high power motor 大功率电动机high slip motor 高转差率电机high speed low-noise synchronous motor 高速低噪音异步电动机high torque AC motor 大转矩交流电动机high torque and low speed motor 大转矩低速电动机high torque motor 高启动转矩电机high voltage motor 高压交流电动机high voltage wound asynchronous motor 高压卷线异步电动机high-capacity motor 大型电动机; 高功率电动机high-compression motor 高压缩发动机high-output three-phase induction motor 高功率三相感应电动机high-slip induction motor 高滑差感应电动机high-slip motor 高滑率电机high-speed motor 高速电动机high-speed servo motor 高速伺服电动机high-voltage motor 高压电动机high-voltage synchronous motor 高压同步电动机hoisting motor 升降电动机home motor 家用电动机homopolar motor 单极电动机horizontal induction motor 卧式感应电动机horizontal motor 卧式电动机horizontal-type motor 卧式发电机horse motor 马拉传动装置horse-drawn motorized duster 马拉机动喷粉机; 马拉式机动喷粉机hot mill motor 热轧电动机hot motor part detection 发动机发热部分探测hot motoring method 热机马达法hydraulic control motor 液压控制马达hydraulic motor drive 液力马达传动hydraulic motor SAE stall pressure 液压马达的SAE制动压力hydraulic motor 水力发动机; 液压发动机; 液压马达; 油压马达hydraulic slave motor 液压马达hydraulic stepping motor 液压步进马达hydraulic traversing electric motor 液压方向机电动机hydraulic-powered wiper motor 液压式风窗刮水器的液力驱动器hydro-electric motor 水力发动机hydro-motor jig 流体传动跳汰机hydro-motor 水压发动机; 液压发动机; 液压马达; 射水发动机hysteresis motor 磁滞电动机; 磁滞式电动机hysteresis synchronous motor 磁滞式同步电动机; 磁滞同步电动机igniter motor 点火发动机immersed torque motor 湿式力矩电动机; 湿式力矩马达immersible motor 浸入型电动机; 潜水电动机impulse motor 脉冲电动机; 脉冲马达impulse stepping motor 脉冲步进电动机increased-safety motor 增安型电动机independent motor drive 单独电动机传动individual drive motor 单独传动电动机individual-drive motor 单独传动电动机induction motor controller 感应电动机控制器induction motor 感应电动机; 异步电动机induction-motor meter 感应式电度表inductor motor 感应子电动机; 作为发电机的感应电动机inductor type synchronous motor 感应子同步电动机in-line (plunger) motor 直列式柱塞电动机in-line motor 直列式马达; 直列式柱塞马达in-line plunger motor 直列式柱塞马达inner tube of pneumatic tyre for motor cycle 摩托车用充气轮胎内胎inside-out motor 旋转电枢式同步电动机; 反结构同步电动机instrument motor 仪表电动机integral horsepower motor 整数马力电动机integrated motor 机内电动机; 积分马达; 积分直流电动机; 整体式电动机integrating motor 积分电动机; 积分马达; 积分直流电动机internally geared motor 内装减速器的电动机internally ventilated motor 内通风式电动机inverse speed motor 反速电动机inversed repulsion motor 反排斥电动机; 反推斥电动机inverse-speed motor 串激特性电动机inverted motor 反结构电动机inverted repulsion motor 反常推斥式电动机; 反用推斥电动机ironless A.C.servo motor 无铁交流伺服电动机Janney motor 轴向回转柱塞式液压电动机; 轴向回转柱塞液压马达jazz the motor 强化发动机jet motor 喷气发动机kick motor 加速发动机Lacour motor 拉库尔电动机large AC three-phase synchronous motor 大型交流三相同步电动机large and medium DC motor 大中型直流电动机large induction motor 大型感应电机large power motor 大功率电动机Latour motor 拉吐尔电动机leaf driving motor 过滤叶片驱动电机leak-proof motor pump 防漏式电动泵lengthened motor lorry 加长载重汽车level-compound excited motor 平复激电动机lift motor 电梯用电动机lifting motor 起重电动机light power motor 小型电动机light rail motor tractor 轻型机车lighting motor-generator set 照明用电动发电机组linear electric motor 直线电动机linear induction motor 线性感应电动机linear motor principle 直线驱动原理linear motor 直线电动机; 线性电动机linear pulse motor 直线步进电动机; 直线脉冲电动机linear reluctance motor 直线式磁阻电动机linear step motor 直线步进电动机linear stepping motor 直线步进电动机linear synchronous motor 线性同步电机line-fed motor 直接馈电电动机line-start motor 线路起动电动机; 直接起动电动机; 直接启动电动机liquid fuel motor 液体燃料发动机liquid motor fuel 液体动力燃料liquid motor 液体火箭发动机liquid-filled motor 充液式电动机load limit motor 负荷限制马达loading motor 加载电机lobed rotor motor 罗茨电动机; 罗茨马达long hour motor 持续运行电动机loom motor 织布机电动机loop motor 环流电动机low power motor 小功率电动机low speed motor 低速电动机low speed synchronous motor 低速同步电机low tension motor starter 低压电动起动机low tension motor 低压电动机low-compression motor 低压缩发动机lower motor neuron disease 下位运动神经元病lower motor neuron lesion 下运动神经元损害lower motor neuron 下运动神经元low-tension motor 低压电动机luffing motor 吊杆俯仰电动机Lundell motor 爪极式电动机; 伦德尔式电动机machine oil pump for motor 摩托车机油泵magnetic clutch motor 磁力离合器电动机magnetic stepping motor 步进电机magnetical stepping motor 磁性步进电机magnet-lagging synchronized motor 磁滞同步电动机mail motor truck 邮政汽车main drive motor 主传动电动机; 主电动机main mill drive motor 轧机主传动电机main motor contactor 主电动接触器main motor 主电动机marine flame-proof three phase asynchronous motor 船用防爆三相异步电动机marine service motor 船用电动机marine-land purpose motor 船-陆两用电机master motor 主驱动电动机medium-sized motor 中型电动机mercury motor type 水银电动机式metal-clad motor 金属加固电动机; 铠装电动机micro-stepping motor 微型步进电动机midget motor 微型电动机; 小型电动机military motor lorry 军用卡车; 军用卡车mill motor 磨坊用电动机minertial motor 小惯量电动机miniature motor 微型电动机mini-motor-home 小型旅宿车mining motor 矿用电动机mist fan motor 喷雾吹风电动机; 喷雾吹风马达mobile motor driven centrifugal pump 移动式机动离心泵model motor 模型电动机; 作为试验样品的电动机modern motor spirit 现代车用汽油Modutrol motor 莫杜特罗尔电动机monocyclic-start induction motor 单相感应电动机monocylicstart induction motor 单周期起动感应电动机monophase asynchronous motor 单相异步电动机monorail motor crab 单轨电动起重机monorail motor hoist 单轨电动绞车motor alternator 电动交流发电机motor amplifier 电机放大器motor analyser 发动机试验机; 发动机试验台motor atomizer 动力弥雾机motor auger 机力螺旋钻motor automatic relay 电机自动继电器motor bark remover 机动剥树皮机motor base (frame) 电动机座motor base (MB) 电动机基础motor base pin 电动机座销轴motor base 电机底座motor battery 电动机电池motor bearing 电动机轴承motor bearings 电机轴承motor bed-plate 电动机机座motor board 电动机配电盘motor boat 摩托艇motor body 发动机壳体motor bogie 自动转向架motor brake magnet 电动机闸磁铁motor branch circuit 电动机分支电路; 电动机馈电支路motor brass alloy 电机黄铜合金motor brass 电动机黄铜motor brush 电动机刷; 电机电刷motor cabinet 电机座motor cable 电动机电缆motor capacity 电动机容量motor car fitter 汽车修配工motor car insurance 汽车保险motor carbon 电动机碳刷; 电机碳刷motor carrier 传送机motor case 电动机壳; 发动机壳体motor casing (frame) 电动机壳motor casing 电机壳; 摩托车外胎motor cavity 电机座位motor chamber diameter 发动机燃烧室直径motor characteristic 电动机特性; 电动机特性曲线motor circuit 动力电路motor coach 长途公共客车motor combination 电动机的组合motor commutator 电动机整流子motor compressor 电动压缩机motor console 发动机试验操纵台motor constant 电动机常数motor control relay 电动机控制继电器motor control 电动机操纵; 电动机电子控制; 电动机控制motor controller 电动机控制器motor cooling jacket 发动机冷却套motor cooling 电动机冷却motor coordinating center 运动协调中枢motor coupling 电动机联轴节motor current-transformer 电动变流器motor cut-out switch 电动机停机开关motor cuts out 发动机停车motor cycle insurance 摩托车保险motor decussation 运动交叉motor disturbance 运动障碍motor drill 手电钻motor drive asphalt pump 电动沥青泵motor drive oil lifter 电动油压升降机motor drive shaft 电动机驱动轴; 马达轴motor drive type 电动机传动型motor drive 电动机拖动; 电动驱动; 电机驱动motor driven blower 电动鼓风机motor driven distributor 电动分配器motor driven hoist 电动绞车motor driven layer radiographic X-ray apparatus 电动断层X射线机motor driven miniature pump set 电动微型水泵机组motor driven psychrometer 电动型通风干湿计motor driven pump 电动泵motor driven saw 电锯motor driven sludge excavator 电动挖泥机motor driven slush pump 电动泥浆泵motor driven starter 电动起动机motor driven switch 电机驱动开关motor driven turbine pump 电动涡轮泵motor driven welding machine 电动焊机; 电动机拖动式焊机motor driving time relay 电动机式时间继电器motor dynamo unit 电动直流发电机组motor dynamo 电动发电机; 电动直流发电机motor dynamometer 电动机功率计motor eccentricity 电机偏心率motor element 电动机元件; 运动元件motor enclosure 电机壳motor end closure 发动机喷口盖motor end plate 运动终板motor excitation 电动机励磁motor exciting current 电动机励磁电流motor fan 电扇motor fault 电动机缺陷motor fiber 运动纤维motor fire brigade vehicle 救火车; 救火车motor for boat 船用发动机motor for kicker and doffer 抖动器和滚筒用电动机motor for wood-working 木工电动机motor foundation 电动机基础motor frame through bolt 电动机长螺栓motor frame 电动机架motor fuel additive 发动机燃料添加剂motor fuel constituent 发动机燃料组成motor function 运动功能; 运动机能motor fuse 电动机熔断器motor gain 电动机增益motor gasoline 动力汽油motor generator arc welder 电动发电机式直流弧焊机motor glider 电动滑翔机motor grab 电动抓斗motor group 电动机组motor head 发动机前端motor hoist 电动葫芦; 电动提升机; 电葫芦motor hotel 汽车饭店motor hull insurance 汽车车身保险motor inclosure 电动机壳Motor Industry Research Association (MIRA) 汽车工业研究协会motor integrating meter 感应式电度表motor interrupter 电动断续器motor launch 汽艇motor line 电动机系列motor load control (MLC) 电动机负载控制motor load 电动机负载motor lorry (truck) 载重汽车motor machine 电动机械motor magnet 电动电磁铁motor manufacturer 电动机制造者motor meter 电动机式电度表; 电动机型仪表; 感应式电表motor method 发动机法; 发动机开车法motor mount ring 发动机安装环motor mower with binder attachment 机动青草割捆机; 带打捆装置的动力割草机motor mower with center drive 中央驱动式动力割草机motor mower with side drive 侧驱式动力割草机motor mower 动力刈草机; 机动割草机motor nozzle 发动机喷管motor nuclei 运动核motor octane number(MON) 马达法辛烷值motor off switch 电动机切断开关motor oil 电机用油; 车用机油; 马达油motor on-off switch 马达启停开关motor petrol 车用汽油motor pinion 电动机小齿轮motor pitch 电动机节距motor plough 自走犁motor plow 机动犁motor point 运动点motor power (output) 电动机功率motor power 发动机推力motor press 机动压力机motor protection against overheat 电动机过热保护; 马达过热保护motor protection relay 电动机保护继电器motor pulley 电动机皮带轮motor pump (MMP) 马达泵motor pump works 电泵厂motor pump 电动泵; 机动泵motor rear end plate 电动机后端盖motor reducer 电动机减速器; 电机减速机; 马达降速器motor reducing gear 电动机减速器; 电机减速机motor reduction unit 降速电动机motor reel 电动机轴motor repair shop 汽车修配厂motor repair 汽车修理motor road 汽车路motor room 电机室motor rotor tester 电机转子试验装置motor rotor 电动机转子motor saw 动力锯motor scooter 低座小摩托车motor scraper 自动铲运机; 自行式铲运机motor shaft 电机轴motor shell 电动机壳motor ship 汽船; 发动机推进飞行器; 内燃机船motor side 电动机侧motor siren 电笛; 电动警笛; 马达报警器motor sleigh 雪橇motor slide rails 电动机导轨motor slip 感应电动机转差率motor specification 电动机规格motor speech area 运动言语中枢motor speed control 电动机转速控制motor speed controller 发动机转速调节器motor speed 电动机转速motor spirit 车用汽油motor spring 汽车弹簧motor sprocket 电动机链轮motor squadron 汽车队motor starter 电动机起动器; 电动起动机; 电动启动器; 电机起动器motor starting and control equipment 电动机起动控制设备motor starting characteristic 发动机起动特性motor starting rheostat 电动机起动变阻器motor stator 电动机定子motor steering 汽车转向motor step 电动机距motor stirrer 电动搅拌器motor stoppage 停车motor 运动原; 电动机; 马达。
步进电机英文
Stepper motorStepper motor is the electric pulse signals into angular displacement or linear displacement of the open-loop stepper motor control element pieces. In the case of non-overloaded, the motor speed, stop position depends only on the pulse frequency and pulse number, regardless of load changes, when the driver receives a step pulse signal, it will drive a stepper motor to Set the direction of rotation of a fixed angle, called the "step angle", which the angle of rotation is fixed step by step operation. Number of pulses can be controlled by controlling the angular displacement, so as to achieve accurate positioning purposes; the same time by controlling the pulse frequency to control the motor rotation speed and acceleration, to achieve speed control purposes.WorkInduction motor is a stepper motor, does it work is the use of electronic circuits, the DC power supply into a time-sharing, multi-phase timing control current, this current stepper motor power supply, the stepper motor to work properly , The drive is sharing power supply for the stepper motor, the polyphase timing controllerAlthough the stepper motor has been widely used, but the stepper motor does not like a normal DC motor, AC motor in the conventional use. It must be double-ring pulse signal, power driver circuit composed of the control system can be used. Therefore, it is not easy with a good stepping motor, which involves mechanical, electrical, electronics and computers, and many other specialized knowledge.As the stepper motor actuators, electromechanical integration, one of the key products, widely used in a variety of automatic control systems. With the development of microelectronics and computer technology, increasing demand for stepper motor, has applications in all areas of the national economy.CategoriesNow more commonly used include the reaction of step motor stepper motor (VR), permanent magnet stepper motor (PM), hybrid stepper motors (HB) and single-phase stepper motor.Permanent magnet stepper motorPermanent magnet stepper motor is generally two-phase, torque, and smaller, usually 7.5 degree step angle or 15 degrees;Permanent magnet stepper motor output torque, dynamic performance, but a large step angle.Reaction Stepper MotorReaction is generally three-phase stepping motor can achieve high torque output, step angle of 1.5 degrees is generally, but the noise and vibration are large. Reaction by the stepper motor rotor magnetic circuit made of soft magnetic materials, a number of the stator phase excitation winding, the use of permeability changes in torque. Step Motor simple structure, low production costs, step angle is small; but the dynamic performance is poor.Hybrid Stepping MotorHybrid Step Motor combines reactive, permanent magnet stepper motors of both, it's asmall step angle, contribute a large, dynamic performance, is currently the highest performance stepper motor. It is also sometimes referred to as Permanent Magnet Induction Stepping Motor. It consists of two phases and the five-phase: the general two-phase step angle of 1.8 degrees and the general five-phase step angle 0.72 degrees. The most widely used Stepper Motor.Stepper motor drive for energy savingThree-phase stepper motor drive special features:■180% low torque output, low frequency characteristics of a good run■Maximum output frequency 600Hz, high-speed motor control■full range of detection of protection (over voltage, under voltage, overload) instantaneous power failure restart■acceleration, deceleration, such as dynamic change in the stall protection function to prevent■Electrical dynamic parameters of automatic recognition function to ensure stability and accuracy of the system■quick response and high-speed shutdown■abundant and flexible input and output interface and control, versatility■use of SMT production and three full-mount anti-paint treatment process, product stability and high■full range of Siemens IGBT power devices using the latest, to ensure the quality of high-qualityBasic principlesUsually for the permanent magnet rotor motor, when current flows through the stator windings, the stator windings produce a magnetic field vector. The magnetic field will lead to a rotor angle of the magnetic field makes the direction of a rotor and the stator's magnetic field direction. When the stator magnetic field vector rotating at an angle. As the rotor magnetic field is also transferred from another perspective. An electrical pulse for each input, the motor turning a point forward. It is the angular displacement of the output and input the number of pulses proportional to speed and pulse frequency is proportional to. Power to change the order of winding, the motor will reverse. Therefore, the number of available control pulse, frequency and power the motor windings of each phase in order to control the stepper motor rotation. Reaction Stepper MotorAs the response to stepping motor works is relatively simple. The following describes the first principle of three-phase stepping motor response.1, the structure: uniformly distributed rotor with many small teeth, the stator excitation windings of three teeth, the geometric axis of the rotor tooth axis in order were staggered. 0,1 / 3 て, 2 / 3 て, (adjacent to the two axes of the rotor tooth pitch distance between the てsaid), that is, with the teeth a relatively homogeneous A, B and staggered tooth 2 to the right 1 / 3 て, C and the right to stagger tooth 3 2 / 3 て, A 'and the tooth 5 is relatively homogeneous, (A' is A, is the gear teeth 5 1) The following is the rotor's expansion plan:2, rotation: If the A-phase power, B, C phase is not energized, the magnetic field,alignment of teeth 1 and A, (without any power of the rotor are the same the following). Such as the B-phase power, A, C phase is not energized, gear 2, and B should be aligned, when the rotor over to the right 1 / 3 て, this time offset teeth 3 and C 1 / 3 て, teeth 4 and A shift (て-1 / 3 te) = 2 / 3 て. Such as the C-phase power, A, B phase is not energized, gear 3, and C should be aligned, this time right off the rotor Youxiang 1 / 3 て, 4 and A gear shift time is 1 / 3 てalignment. Such as the A-phase power, B, C phase is not energized, 4 and A-aligned teeth, the rotor Youxiang right over 1 / 3 てso after A, B, C, A are energized, gear 4 (ie, the previous tooth 1 teeth) to the A-phase, rotor to the right around a pitch, if you continue to press the A, B, C, A ... ... power, the motor for each step (per pulse) 1 / 3 て, Rotate Right. Such as by A, C, B, A ... ... power, the motor to reverse. This shows that: the location and speed of motor conduction times by the (number of pulses) and frequency into one relationship. The direction determined by the conductivity of the order. However, out of torque, smooth, noise and reduce the angle considerations. Often with A-AB-B-BC-C-CA-A this conductive state, so that each step the original 1 / 3 てchanged to 1 / 6 て. Even through different combinations of two-phase current, so 1 / 3 てinto 1 / 12 て, 1 / 24, te, which is the basic theory of the motor-driven basis for subdivision. Easily introduced: m phase on the stator excitation windings, the axis of the rotor tooth axis were offset 1 / m, 2 / m ... ... (m-1) / m, 1. And conductivity at a certain phase sequence reversing motor can be controlled - this is the rotation of the physical conditions. As long as we meet this condition can theoretically create any phase stepper motor, because of cost, and many other considerations, the market generally two, three, four, five-phase is more.3, the torque: the motor once energized, will produce between the stator and rotor magnetic field (magnetic flux Ф) when the rotor and stator stagger angle to produce force F and (dФ / dθ) is proportional to S the magnetic flux Ф = Br * S Br for the flux density, F and S for the magnetic area of L * D * Br core is proportional to L, effective length, D is rotor diam eter Br = N • I / RN • I was excited winding ampere turns (current x turns) R for the magnetic resistance. Torque = force * radius of the torque and the motor turns the effective volume * An * is proportional to the flux density (only consider the linear state), therefore, the greater the effective volume of the motor, the greater the excitation ampere turns, the smaller air gap between stator and rotor, the motor torque, and vice versa.Induction Stepping Motor1, features: Induction, compared with the traditional reactive, structural reinforced with a permanent magnet rotor, in order to provide the working point of soft magnetic materials, and the stator excitation magnetic field changes only need to provide to provide the operating point of the consumption of magnetic materials energy, so the motor efficiency, current, low heat. Due to the presence of permanent magnets, the motor has a strong EMF, the damping effect of its own good, it is relatively stable during operation, low noise, low frequency vibration. Induction can be seen as somewhat low-speed synchronous motor. A four-phase motor can be used for four-phase operation, but also can be used for two-phase operation. (Must be bipolarvoltage drive), while the motor is not so reactive. For example: four phase, eight-phase operation (A-AB-B-BC-C-CD-D-DA-A) can use two-phase eight-shot run. Not difficult to find the conditions for C =, D =. a two-phase motor's internal winding consistent with the four-phase motors, small power motors are generally directly connected to the second phase, the power of larger motor, in order to facilitate the use and flexible to change the dynamic characteristics of the motor, its external connections often lead to eight (four-phase), so that when used either as a four-phase motors used, can be used for two-phase motor winding in series or parallel.2, classificationInduction motors can be divided in phases: two-phase motor, three phase motor, four-phase motor, five-phase motor. The frame size (motor diameter) can be divided into: 42BYG (BYG the Induction Stepping motor code), 57BYG, 86BYG, 110BYG, (international standard), and like 70BYG, 90BYG, 130BYG and so are the national standards.3, the stepper motor phase number of static indicators of terms: very differently on the N, S the number of magnetic field excitation coil. Common m said. Beat number: complete the necessary cyclical changes in a magnetic field pulses or conducting state with n said, or that turned a pitch angle of the motor pulses needed to four-phase motor, for example, a four-phase four-shot operation mode that AB -BC-CD-DA-AB, shot eight four-phase operation mode that A-AB-B-BC-C-CD-D-DA-A. Step angle: corresponds to a pulse signal, the angular displacement of the rotor turned with θ said. θ = 360 degrees(the rotor teeth number of J * run shot), the conventional two, four-phase, the rotor teeth 50 tooth motor as an example. Four step run-time step angle θ = 360 ° / (50 * 4) = 1.8 degrees (commonly called the whole step), eight-shot running step angle θ = 360 ° / (50 * 8) = 0.9 degrees (commonly known as half step.) Location torque: the motor is not energized in the state, its locked rotor torque (as well as by the magnetic field profile of harmonics caused by mechanical error) static torque: the motor under the rated static electricity, the motor without rotation, the motor shaft locking torque. The motor torque is a measure of volume (geometry) standards, and drive voltage and drive power, etc. has nothing to do. Although the static torque is proportional to the electromagnetic magnetizing ampere turns, and fixed air gap between the rotor teeth on, but over-use of reduced air gap, increase the excitation ampere-turns to increase the static torque is not desirable, this will cause the motor heating and mechanical noise.4, the dynamic indicators and terminology:1, step angle accuracy: turn a stepper motor step angle for each actual value with the theoretical value of the error. Expressed as a percentage: Error / Step Angle * 100%. Its value is the number of different running different beat, four beat running should be within 5%, eight runs should take less than 15%.2 step: the motor running operation steps, is not equal to the theoretical number of steps. Called the step.3, offset angle: the axis of the rotor tooth offset angle of the axis of the stator teeth, the motor is running there will be misalignment angle, the error caused by themisalignment angle, using division drive can not be solved.4, the maximum no-load starting frequency: a drive motor in the form of voltage and rated current, in the case without load, the maximum frequency can be started directly.5, the maximum operating frequency of load: a drive motor in the form of voltage and rated current, the motor maximum speed with no load frequency.6, running torque-frequency characteristics: the motor under test conditions in a measured frequency of operation between the output torque and running torque curve is called the frequency characteristic curve which is the motor number of the most important dynamic is the fundamental basis for motor selection. As shown below: There used to frequency characteristics of other features, starting frequency characteristics. Electrical Once selected, the motor torque to determine the static and dynamic torque is not the case, the motor torque depends on the dynamics of the average motor current (rather than static current), the average current increases, the greater the output torque of the motor, that motor frequency characteristics of the more hard. As shown below: where the maximum curve 3 current, or voltages; curve a minimum current, or voltage is the lowest curve and the load maximum speed of the intersection point of the load. For the average current, voltage increase as much as possible, so that the use of small inductor high current motor.7, the resonance point of the motor: stepping motor has a fixed resonance region, two, four-phase Induction in the resonance region is generally between 180-250pps (1.8 degree step angle) or about the 400pps (step angle 0.9 degrees), the higher the motor drive voltage, motor current increases, the lighter the load, the smaller the size the motor, the resonance shift upward, and vice versa, the motor output torque is large, yet further, and the whole system noise reduction, the general operating point should be offset more resonance.8, motor reversing control: timing is energized when the motor windings AB-BC-CD-DA or () is a positive turn, power the timing for the DA-CD-BC-AB or () when reversed.Some of the basic parameters of the stepper motorNatural step angle motorIt said each of the control system sends a pulse signal, the motor rotation angle. Motor factory, a step angle is given a value, such as 86BYG250A motors is given in 0.9 ° / 1.8 ° (half-step work that is 0.9 °, when the work of the whole step 1.8 °), the step angle can be called 'natural step angle motor', which is not necessarily true when the actual work the motor step angle, the real step angle and drive on.Stepper motor step angle is usually the general computing β calculated as follows.β= 360 ° / (Z • m • K)Where β-stepper motor step angle;Z-rotor teeth;m-phase stepper motor number;K-control factor, the film is the ratio of the number of coefficients with the phase numberPhase stepper motorRefers to the number of the motor coil group, the commonly used two-phase, three phase, four-phase, five-phase stepper motor. Different number of motor phases, the step angle is different, the general two-phase motor step angle of 0.9 °/ 1.8 °, three-phase for the 0.75 ° / 1.5 °, five-phase for the 0.36 ° / 0.72 °. In the absence of sub-drive, the user select a different number of phases depends mainly on the stepper motor step angle to meet their own requirements. If you use the sub-drive, the 'phases' will become meaningless, the user simply changes in the subdivision number on the drive, you can change the step angle.Holding torque (HOLDING TORQUE)Stepper motor is energized but no rotation, the stator locked rotor torque. It is the stepper motor one of the most important parameters, usually when the stepper motor torque at low speed near the holding torque. As the stepper motor's output torque increases with the speed and continuous attenuation, output power increases with the speed change, so keep the torque stepper motor to become a measure of one of the most important parameters. For example, when people say 2N.m the stepper motor in case of no special note is the holding torque of the stepper motor for the 2N.m. DETENT TORQUE:Stepper motor is not energized, the stator locked rotor torque. DETENT TORQUE translation in the country there is no uniform way, easy to misunderstand us; the reaction is not a permanent magnet stepper motor rotor material, so it does not DETENT TORQUE.Characteristics of the stepper motor1. The general accuracy of the stepper motor step angle of 3-5%, and not cumulative.2. Appearance of the stepper motor to allow the maximum temperature.Stepper motor causes the motor temperature is too high the first magnetic demagnetization, resulting in loss of torque down even further, so the motor surface temperature should be the maximum allowed depending on the motor demagnetization of magnetic material points; Generally speaking, the magnetic demagnetization points are above 130 degrees Celsius, and some even as high as 200 degrees Celsius, so the stepper motor surface temperature of 80-90 degrees Celsius is normal.3. Stepper motor torque will decrease with the increase of speed.When the stepper motor rotates, the motor winding inductance of each phase will form a reverse electromotive force; the higher the frequency the greater the back emf. In its role, the motor with frequency (or speed) increases with the phase current decreases, resulting in decreased torque.4. Low-speed stepper motor can operate normally, but if not higher than a certain speed to start, accompanied by howling.Stepper motor has a technical parameters: no-load starting frequency, ie the stepper motor with no load to start the normal pulse frequency, pulse frequency is higher than the value if the motor does not start, you may lose steps or stall occurs. In the case of a load, start frequency should be lower. If you want the motor to achieve high-speed rotation, the pulse frequency should speed up the process, which started lower frequency, and then rise by a certain acceleration of the desired frequency(motor speed from low rise to high-speed).Stepper motor with its significant features, in the era of digital manufacturing play an important purpose. Along with the different development of digital technology and the stepper motor itself, improvements in technology, the stepper motor will be applied in more fields.。
步进电机英语介绍ppt
视频:
Closed-loop control
The closed-loop control of the stepping motor is used to determine the phase transformation, which is suitable for the position of the rotor. The accuracy and stability of the system can greatly improve the performance of the stepping motor. 步进电动机的闭环控制是采用位置反馈和
introduce:
Stepping motor is a synchronous motor with intermittent operation, which is a function of the digital control system.
步进电机本质上属于断续运转的同步电机, 是数字控制系统中的一种执行元件。
synchronous [ˈsɪŋkrənəs] intermittent operation [ˌɪntəˈmitənt ˌɔpəˈreiʃən] digital [ˈdɪdʒɪtl]
The function is to convert the input pulse signal into the corresponding angular displacement or linear displacement. The motor rotates a corner or a step. 其功用是将输入的脉冲信号转换为相应的 角位移或直线位移,给定一个脉冲信号, 电机就转动一个角度或前进一步。
步进电机控制系统外文翻译
步进电机的振荡、不稳定以及控制摘要:本文介绍了一种分析永磁步进电机不稳定性的新颖方法。
结果表明,该种电机有两种类型的不稳定现象:中频振荡和高频不稳定性。
非线性分叉理论是用来说明局部不稳定和中频振荡运动之间的关系。
一种新型的分析介绍了被确定为高频不稳定性的同步损耗现象。
在相间分界线和吸引子的概念被用于导出数量来评估高频不稳定性。
通过使用这个数量就可以很容易地估计高频供应的稳定性。
此外,还介绍了稳定性理论。
广义的方法给出了基于反馈理论的稳定问题的分析。
结果表明,中频稳定度和高频稳定度可以提高状态反馈。
关键词:步进电机,不稳定,非线性,状态反馈。
1. 介绍步进电机是将数字脉冲输入转换为模拟角度输出的电磁增量运动装置。
其内在的步进能力允许没有反馈的精确位置控制。
也就是说,他们可以在开环模式下跟踪任何步阶位置,因此执行位置控制是不需要任何反馈的。
步进电机提供比直流电机每单位更高的峰值扭矩;此外,它们是无电刷电机,因此需要较少的维护。
所有这些特性使得步进电机在许多位置和速度控制系统的选择中非常具有吸引力,例如如在计算机硬盘驱动器和打印机,代理表,机器人中的应用等.尽管步进电机有许多突出的特性,他们仍遭受振荡或不稳定现象。
这种现象严重地限制其开环的动态性能和需要高速运作的适用领域。
这种振荡通常在步进率低于1000脉冲/秒的时候发生,并已被确认为中频不稳定或局部不稳定[1],或者动态不稳定[2]。
此外,步进电机还有另一种不稳定现象,也就是在步进率较高时,即使负荷扭矩小于其牵出扭矩,电动机也常常不同步。
该文中将这种现象确定为高频不稳定性,因为它以比在中频振荡现象中发生的频率更高的频率出现。
高频不稳定性不像中频不稳定性那样被广泛接受,而且还没有一个方法来评估它。
中频振荡已经被广泛地认识了很长一段时间,但是,一个完整的了解还没有牢固确立。
这可以归因于支配振荡现象的非线性是相当困难处理的。
大多数研究人员在线性模型基础上分析它[1]。
机床常见英语英汉对照
机床行业常见英语英汉对照(1):按英文字母排序3-Jaws indexing spacers 三爪、分割工具头A.T.C.system 加工中心机刀库Aluminum continuous melting & holding furnaces 连续溶解保温炉Balancing equipment 平衡设备Bayonet 卡口Bearing fittings 轴承配件Bearing processing equipment 轴承加工机Bearings 轴承Belt drive 带传动Bending machines 弯曲机Blades 刀片Blades,saw 锯片Bolts,screws & nuts 螺栓,螺帽及螺丝Boring heads 搪孔头Boring machines 镗床Cable making tools 造线机Casting,aluminium 铸铝Casting,copper 铸铜Casting,gray iron 铸灰口铁Casting,malleable iron 可锻铸铁Casting,other 其他铸造Casting,steel 铸钢Chain drive 链传动Chain making tools 造链机Chamfer machines 倒角机Chucks 夹盘Clamping/holding systems 夹具/支持系统CNC bending presses 电脑数控弯折机CNC boring machines 电脑数控镗床CNC drilling machines 电脑数控钻床CNC EDM wire-cutting machines 电脑数控电火花线切削机CNC electric discharge machines 电脑数控电火花机CNC engraving machines 电脑数控雕刻机CNC grinding machines 电脑数控磨床CNC lathes 电脑数控车床CNC machine tool fittings 电脑数控机床配件CNC milling machines 电脑数控铣床CNC shearing machines 电脑数控剪切机CNC toolings CNC刀杆CNC wire-cutting machines电脑数控线切削机Conveying chains 输送链Coolers 冷却机Coupling 联轴器Crimping tools 卷边工具Cutters 刀具Cutting-off machines 切断机Diamond cutters 钻石刀具Dicing saws 晶圆切割机Die casting dies 压铸冲模Die casting machines 压铸机Dies-progressive 连续冲模Disposable toolholder bits 舍弃式刀头Drawing machines 拔丝机Drilling machines 钻床Drilling machines bench 钻床工作台Drilling machines,high-speed 高速钻床Drilling machines,multi-spindle 多轴钻床Drilling machines,radial 摇臂钻床Drilling machines,vertical 立式钻床drills 钻头Electric discharge machines(EDM) 电火花机Electric power tools 电动刀具Engraving machines 雕刻机Engraving machines,laser 激光雕刻机Etching machines 蚀刻机Finishing machines 修整机Fixture 夹具Forging dies 锻模Forging,aluminium 锻铝Forging,cold 冷锻Forging,copper 铜锻Forging,other 其他锻造Forging,steel 钢锻Foundry equipment 铸造设备Gear cutting machines 齿轮切削机Gears 齿轮Gravity casting machines 重力铸造机Grinder bench 磨床工作台Grinders,thread 螺纹磨床Grinders,tools & cutters 工具磨床Grinders,ultrasonic 超声波打磨机Grinding machines 磨床Grinding machines,centerless 无心磨床Grinding machines,cylindrical 外圆磨床Grinding machines,universal 万能磨床Grinding tools 磨削工具Grinding wheels 磨轮Hand tools 手工具Hard/soft and free expansion sheet making plant 硬(软)板(片)材及自由发泡板机组Heat preserving furnaces 保温炉Heating treatment funaces 熔热处理炉Honing machines 搪磨机Hydraulic components 液压元件Hydraulic power tools 液压工具Hydraulic power units 液压动力元件Hydraulic rotary cylinders 液压回转缸Jigs 钻模Lapping machines 精研机Lapping machines,centerless 无心精研机Laser cutting 激光切割Laser cutting for SMT stensil 激光钢板切割机Lathe bench 车床工作台Lathes,automatic 自动车床Lathes,heavy-duty 重型车床Lathes,high-speed 高速车床Lathes,turret 六角车床Lathes,vertical 立式车床Lubricants 润滑液Lubrication Systems 润滑系统Lubricators 注油机Machining centers,general 通用加工中心Machining centers,horizontal 卧式加工中心Machining centers,horizontal & vertical 卧式及立式加工中心Machining centers,vertical 立式加工中心Machining centers,vertical double-column type 立式双柱加工中心Magnetic tools 磁性工具Manifolds 集合管Milling heads 铣头Milling machines 铣床Milling machines,bed type 床身式铣床Milling machines,duplicating 仿形铣床Milling machines,horizontal 卧式铣床Milling machines,turret vertical 六角立式铣床Milling machines,universal 万能铣床Milling machines,vertical 立式铣床Milling machines,vertical & horizontal 立式及卧式铣床Mold & die components 模具单元Mold changing systems 换模系统Mold core 模芯Mold heaters/chillers 模具加热器/冷却器Mold polishing/texturing 模具打磨/磨纹Mold repair 模具维修Molds 模具Nail making machines 造钉机Oil coolers 油冷却器Overflow cutting machines for aluminium wheels 铝轮冒口切断机P type PVC waterproof rolled sheet making plant P型PVC高分子防水PCB fine piecing systems 印刷电器板油压冲孔脱料系统Pipe & tube making machines 管筒制造机Planing machines 刨床Planing machines vertical 立式刨床Pneumatic hydraulic clamps 气油压虎钳Pneumatic power tools 气动工具Powder metallurgic forming machines 粉末冶金成型机Presses,cold forging 冷锻冲压机presses,crank 曲柄压力机Presses,eccentric 离心压力机Presses,forging 锻压机Presses,hydraulic 液压冲床Presses,knuckle joint 肘杆式压力机Presses,pneumatic 气动冲床Presses,servo 伺服冲床Presses,transfer 自动压力机Pressing dies 压模Punch formers 冲子研磨器Quick die change systems 速换模系统Quick mold change systems 快速换模系统Reverberatory furnaces 反射炉Rollers 滚筒Rolling machines 辗压机Rotary tables 转台Sawing machines 锯床Sawing machines,band 带锯床Saws,band 带锯Saws,hack 弓锯Saws,horizontal band 卧式带锯Saws,vertical band 立式带锯shafts 轴Shapers 牛头刨床Shearing machines 剪切机Sheet metal forming machines 金属板成型机Sheet metal working machines 金属板加工机Slotting machines 插床spindles 主轴Stamping parts 冲压机Straightening machines 矫直机Switches & buttons 开关及按钮Tapping machines 攻螺丝机Transmitted chains 传动链Tube bending machines 弯管机Vertical hydraulic broaching machine 立式油压拉床Vises 虎钳Vises,tool-maker 精密平口钳Wheel dressers 砂轮修整器Woven-Cutting machines 织麦激光切割机Wrenches 扳手(2):按中文拼音字母排序铝轮冒口切断机Overflow cutting machines for aluminium wheels离心压力机Presses,eccentric六角立式铣床Milling machines,turret vertical六角车床Lathes,turret螺栓,螺帽及螺丝Bolts,screws & nuts螺纹磨床Grinders,thread冷却机Coolers冷锻Forging,cold 冷锻冲压机Presses,cold forging立式双柱加工中心Machining centers,vertical double-column type立式铣床Milling machines,vertical立式油压拉床Vertical hydraulic broaching machine立式刨床Planing machines vertical立式车床Lathes,vertical立式带锯Saws,vertical band立式加工中心Machining centers,vertical立式及卧式铣床Milling machines,vertical & horizontal立式钻床Drilling machines,vertical联轴器Coupling连续溶解保温炉Aluminum continuous melting & holding furnaces连续冲模Dies-progressive链传动Chain drive切断机Cutting-off machinesCNC刀杆CNC toolings曲柄压力机presses,crank修整机Finishing machines舍弃式刀头Disposable toolholder bits润滑系统Lubrication Systems润滑液Lubricants熔热处理炉Heating treatment funaces三爪、分割工具头3-Jaws indexing spacers 伺服冲床Presses,servo输送链Conveying chains手工具Hand tools砂轮修整器Wheel dressers蚀刻机Etching machines外圆磨床Grinding machines,cylindrical搪磨机Honing machines搪孔头Boring heads卧式铣床Milling machines,horizontal卧式带锯Saws,horizontal band卧式加工中心Machining centers,horizontal 卧式及立式加工中心Machining centers,horizontal & vertical万能铣床Milling machines,universal万能磨床Grinding machines,universal镗床Boring machines弯曲机Bending machines弯管机Tube bending machines通用加工中心Machining centers,general铜锻Forging,copper铣头Milling heads铣床Milling machines无心磨床Grinding machines,centerless无心精研机Lapping machines,centerless压模Pressing dies压铸冲模Die casting dies压铸机Die casting machines油冷却器Oil coolers造链机Chain making tools造线机Cable making tools造钉机Nail making machines印刷电器板油压冲孔脱料系统PCB fine piecing systems摇臂钻床Drilling machines,radial硬(软)板(片)材及自由发泡板机组Hard/soft and free expansion sheet making plant辗压机Rolling machines液压元件Hydraulic components液压冲床Presses,hydraulic液压动力元件Hydraulic power units液压工具Hydraulic power tools液压回转缸Hydraulic rotary cylindersP型PVC高分子防水P type PVC waterproof rolled sheet making plant刨床Planing machines牛头刨床Shapers其他铸造Casting,other其他锻造Forging,other模芯Mold core模具Molds模具维修Mold repair模具打磨/磨纹Mold polishing/texturing模具单元Mold & die components模具加热器/冷却器Mold heaters/chillers磨轮Grinding wheels磨削工具Grinding tools磨床Grinding machines磨床工作台Grinder bench平衡设备Balancing equipment气油压虎钳Pneumatic hydraulic clamps气动冲床Presses,pneumatic 气动工具Pneumatic power tools轴shafts轴承Bearings轴承配件Bearing fittings轴承加工机Bearing processing equipment 肘杆式压力机Presses,knuckle joint铸铝Casting,aluminium铸铜Casting,copper铸造设备Foundry equipment铸钢Casting,steel铸灰口铁Casting,gray iron织麦激光切割机Woven-Cutting machines 重力铸造机Gravity casting machines重型车床Lathes,heavy-duty主轴spindles扳手Wrenches拔丝机Drawing machines保温炉Heat preserving furnaces插床Slotting machines齿轮Gears齿轮切削机Gear cutting machines冲压机Stamping parts冲子研磨器Punch formers超声波打磨机Grinders,ultrasonic车床工作台Lathe bench磁性工具Magnetic tools传动链Transmitted chains床身式铣床Milling machines,bed type带传动Belt drive带锯Saws,band带锯床Sawing machines,band电脑数控镗床CNC boring machines电脑数控弯折机CNC bending presses电脑数控铣床CNC milling machines电脑数控线切削机CNC wire-cutting machines电脑数控磨床CNC grinding machines电脑数控车床CNC lathes电脑数控电火花线切削机CNC EDM wire-cutting machines电脑数控电火花机CNC electric discharge machines电脑数控雕刻机CNC engraving machines 电脑数控机床配件CNC machine toolfittings电脑数控剪切机CNC shearing machines电脑数控钻床CNC drilling machines电动刀具Electric power tools电火花机Electric discharge machines(EDM) 雕刻机Engraving machines刀片Blades刀具Cutters倒角机Chamfer machines多轴钻床Drilling machines,multi-spindle锻铝Forging,aluminium锻压机Presses,forging锻模Forging dies仿形铣床Milling machines,duplicating粉末冶金成型机Powder metallurgic forming machines反射炉Reverberatory furnaces钢锻Forging,steel高速车床Lathes,high-speed高速钻床Drilling machines,high-speed管筒制造机Pipe & tube making machines滚筒Rollers工具磨床Grinders,tools & cutters攻螺丝机Tapping machines弓锯Saws,hack虎钳Vises换模系统Mold changing systems夹盘Chucks夹具Fixture夹具/支持系统Clamping/holding systems剪切机Shearing machines加工中心机刀库A.T.C.system激光切割Laser cutting激光雕刻机Engraving machines,laser激光钢板切割机Laser cutting for SMT stensil集合管Manifolds矫直机Straightening machines金属板成型机Sheet metal forming machines 金属板加工机Sheet metal working machines锯片Blades,saw锯床Sawing machines卷边工具Crimping tools 晶圆切割机Dicing saws精密平口钳Vises,tool-maker精研机Lapping machines可锻铸铁Casting,malleable iron快速换模系统Quick mold change systems 卡口Bayonet开关及按钮Switches & buttons钻石刀具Diamond cutters钻头drills钻模Jigs钻床Drilling machines钻床工作台Drilling machines bench自动压力机Presses,transfer金属切削metal cutting机床machine tool金属工艺学technology of metals刀具cutter摩擦friction联结link传动drive/transmission轴shaft弹性elasticity频率特性frequency characteristic误差error响应response定位allocation机床夹具jig动力学dynamic运动学kinematic静力学static分析力学analyse mechanics拉伸pulling压缩hitting剪切shear扭转twist弯曲应力bending stress强度intensity三相交流电three-phase AC磁路magnetic circles变压器transformer异步电动机asynchronous motor几何形状geometrical精度precision正弦形的sinusoid交流电路AC circuit机械加工余量machining allowance变形力deforming force变形deformation应力stress硬度rigidity热处理heat treatment退火anneal正火normalizing脱碳decarburization渗碳carburization电路circuit半导体元件semiconductor element反馈feedback发生器generator直流电源DC electrical source门电路gate circuit逻辑代数logic algebra外圆磨削external grinding内圆磨削internal grinding平面磨削plane grinding变速箱gearbox离合器clutch绞孔fraising绞刀reamer螺纹加工thread processing螺钉screw铣削mill铣刀milling cutter功率power工件workpiece齿轮加工gear mechining齿轮gear主运动main movement主运动方向direction of main movement进给方向direction of feed进给运动feed movement合成进给运动resultant movement of feed合成切削运动resultant movement of cutting 合成切削运动方向direction of resultant movement of cutting切削深度cutting depth前刀面rake face刀尖nose of tool 前角rake angle后角clearance angle龙门刨削planing主轴spindle主轴箱headstock卡盘chuck加工中心machining center车刀lathe tool车床lathe钻削镗削bore车削turning磨床grinder基准benchmark钳工locksmith锻forge压模stamping焊weld拉床broaching machine拉孔broaching装配assembling铸造found流体动力学fluid dynamics流体力学fluid mechanics加工machining液压hydraulic pressure切线tangent机电一体化mechanotronics mechanical-electrical integration气压air pressure pneumatic pressure稳定性stability介质medium液压驱动泵fluid clutch液压泵hydraulic pump阀门valve失效invalidation强度intensity载荷load应力stress安全系数safty factor可靠性reliability螺纹thread螺旋helix键spline销pin滚动轴承rolling bearing滑动轴承sliding bearing弹簧spring制动器arrester brake十字结联轴节crosshead联轴器coupling链chain皮带strap精加工finish machining粗加工rough machining变速箱体gearbox casing腐蚀rust氧化oxidation磨损wear耐用度durability随机信号random signal离散信号discrete signal超声传感器ultrasonic sensor集成电路integrate circuit挡板orifice plate残余应力residual stress套筒sleeve扭力torsion冷加工cold machining电动机electromotor汽缸cylinder过盈配合interference fit热加工hotwork摄像头CCD camera倒角rounding chamfer优化设计optimal design工业造型设计industrial moulding design有限元finite element滚齿hobbing插齿gear shaping伺服电机actuating motor铣床milling machine钻床drill machine镗床boring machine步进电机stepper motor丝杠screw rod导轨lead rail组件subassembly可编程序逻辑控制器Programmable Logic Controller PLC电火花加工electric spark machining电火花线切割加工electrical discharge wire - cutting相图phase diagram热处理heat treatment固态相变solid state phase changes有色金属nonferrous metal陶瓷ceramics合成纤维synthetic fibre电化学腐蚀electrochemical corrosion车架automotive chassis悬架suspension转向器redirector变速器speed changer板料冲压sheet metal parts孔加工spot facing machining车间workshop工程技术人员engineer气动夹紧pneuma lock数学模型mathematical model画法几何descriptive geometry机械制图Mechanical drawing投影projection视图view剖视图profile chart标准件standard component零件图part drawing装配图assembly drawing尺寸标注size marking技术要求technical requirements刚度rigidity内力internal force位移displacement截面section疲劳极限fatigue limit断裂fracture塑性变形plastic distortion脆性材料brittleness material刚度准则rigidity criterion垫圈washer垫片spacer直齿圆柱齿轮straight toothed spur gear斜齿圆柱齿轮helical-spur gear直齿锥齿轮straight bevel gear运动简图kinematic sketch齿轮齿条pinion and rack蜗杆蜗轮worm and worm gear虚约束passive constraint曲柄crank摇杆racker凸轮cams共轭曲线conjugate curve范成法generation method定义域definitional domain值域range导数\\微分differential coefficient求导derivation定积分definite integral不定积分indefinite integral曲率curvature偏微分partial differential毛坯rough游标卡尺slide caliper千分尺micrometer calipers攻丝tap二阶行列式second order determinant逆矩阵inverse matrix线性方程组linear equations概率probability随机变量random variable排列组合permutation and combination气体状态方程equation of state of gas动能kinetic energy势能potential energy机械能守恒conservation of mechanical energy动量momentum桁架truss轴线axes余子式cofactor逻辑电路logic circuit触发器flip-flop脉冲波形pulse shape数模digital analogy液压传动机构fluid drive mechanism机械零件mechanical parts淬火冷却quench 淬火hardening回火tempering调质hardening and tempering磨粒abrasive grain结合剂bonding agent砂轮grinding wheel舍弃式刀头Di osabletoolholderbits润滑系统Lubricatio ystems润滑液Lubricants熔热处理炉Heatingtreatmentfunaces三爪、分割工具头3-Jawsindexing acers伺服冲床Pre es,servo输送链Conveyingchai手工具Handtools砂轮修整器Wheeldre ers蚀刻机Etchingmachines外圆磨床Grindingmachines,cylindrical搪磨机Honingmachines搪孔头Boringheads卧式铣床Millingmachines,horizontal卧式带锯Saws,horizontalband卧式加工中心Machiningcenters,horizontal 卧式及立式加工中心Machiningcenters,horizontal&am amp amp vertical万能铣床Millingmachines,universal万能磨床Grindingmachines,universal镗床Boringmachines弯曲机Bendingmachines弯管机Tubebendingmachines通用加工中心Machiningcenters,general铜锻Forging,co er铣头Millingheads铣床Millingmachines无心磨床Grindingmachines,centerle无心精研机La ingmachines,centerle压模Pre ingdies压铸冲模Diecastingdies压铸机Diecastingmachines油冷却器Oilcoolers造链机Chainmakingtools弯管机Tubebendingmachines通用加工中心Machiningcenters,general铜锻Forging,co er铣头Millingheads铣床Millingmachines无心磨床Grindingmachines,centerle无心精研机La ingmachines,centerle压模Pre ingdies压铸冲模Diecastingdies压铸机Diecastingmachines油冷却器Oilcoolers手工具Handtools砂轮修整器Wheeldre ers蚀刻机Etchingmachines外圆磨床Grindingmachines,cylindrical搪磨机Honingmachines搪孔头Boringheads卧式铣床Millingmachines,horizontal卧式带锯Saws,horizontalband卧式加工中心Machiningcenters,horizontal 卧式及立式加工中心Machiningcenters,horizontal&am amp amp vertical万能铣床Millingmachines,universal万能磨床Grindingmachines,universal镗床Boringmachines修整机Finishingmachines舍弃式刀头Di osabletoolholderbits润滑系统Lubricatio ystems润滑液Lubricants熔热处理炉Heatingtreatmentfunaces三爪、分割工具头3-Jawsindexing acers伺服冲床Pre es,servo输送链Conveyingchai手工具Handtools砂轮修整器Wheeldre ers蚀刻机Etchingmachines外圆磨床Grindingmachines,cylindrical搪磨机Honingmachines搪孔头Boringheads卧式铣床Millingmachines,horizontal卧式带锯Saws,horizontalband卧式加工中心Machiningcenters,horizontal 卧式及立式加工中心Machiningcenters,horizontal&am amp amp vertical万能铣床Millingmachines,universal 万能磨床Grindingmachines,universal 镗床Boringmachines弯曲机Bendingmachines弯管机Tubebendingmachines常见数控机床参数英语词汇AC 交流电AMP 安培APC 自动托盘交换装置APL 自动部件装载机ASCII 美国信息交换标准法规ATC 自动刀具交换装置ATC FWD 自动刀具交换装置前进ATC REV 自动刀具交换装置后退AWG 美国线规BHCS 圆头帽螺钉CAD 计算机辅助设计CAM 计算机辅助制造(辅助加工)CB 断路开关CC 立方厘米CCW 逆时针CFM 每分钟立方英尺CNC 计算机数控CNCR SPINDLE 与轴运动同步的芯轴CRC 循环冗余码校验数字CRT 阴极射线管CTS 清除发送CW 顺时针DB 牵引杆DC 直流电DGNOS 诊断DHCP 动态主机配置协议DIR 目录DNC 直接数字控制DOS 磁盘操作系统DTE 数据终端设备ENA CNVR 启动输送机EOB 块结束EOF 文件结束EPROM 可擦可编程只读存储器E-STOP 紧急停机FADAL 其他人FHCS 平头帽螺钉FT 英尺FU 保险丝FWD 前进GA 量规HAAS 正确的刀具HHB 六角头螺钉HP 马力HS 卧式系列加工中心ID 内径IGBT 隔离栅双极晶体管IN 英寸IOPCB 输入输出印刷电路板LAN 局域网LB 磅LED 发光二极管LO CLNT 冷却剂低压LOW AIR PR 低气压LVPS 低电压电源MB 兆字节(1百万)MCD RL Y BRD M-代码继电器盘MDI 手动数据输入MEM 存储器M-FIN M-代码完成MM 毫米MOCON 电动机控制器MOTIF 电动机接口MSG 信息MSHCP 公制插座帽螺钉NC 数字控制NC 常闭合NO 常开OD 外径OPER 操作员P 袋PARAM 参数PCB 印制电路板PGM 程序POR 通电复位POSIT 位置PROG 程序PSI 每平方英寸磅PWM 脉冲宽度调制RAM 随机存取存储器REPT RIG TAP 围盘轧制刚性螺丝攻RET 返回,回车REV CNVR 回动输送机RJH 遥控摇柄RPDBDN 旋转式托盘拉杆放下RPDBUP 旋转式托盘拉杆提起RPM 每分钟转数RIS 请求输送RXD 接收数据S 芯轴转速SDIST 伺服机构分配印制电路板SFM 每分钟平方英尺SHCS 套筒扳手头帽螺钉SIO 串行输入/输出SKBIF 串行键盘接口印制电路板SMTC 侧挂式刀具交换装置SP 芯轴T 刀具编号TC 刀具交换装置TIR 总指示偏转TNC 刀尖偏差TRP 刀具释放活塞IS 尾架ISC 通过芯轴的冷却剂TXD 发送数据VDI 德国工程师协会VF 立式铣床(第一台)VF-E 立式铣床-扩展型VMC 立式加工中心WAN 广域网。
步进电机 英文翻译
郑州航空工业管理学院英文翻译2014 届电气工程及其自动化专业班级姓名学号指导教师职称二О一四年 2 月22 日Stepper motorStepper motor is the electrical pulse signal into angular displacement or linear displacement of an open loop stepper motor control element pieces . In the case of non- overloading , motor speed , stopped position depends only on the number of pulse frequency and pulse signals , which are not affected by changes in load , when stepper drive receives a pulse signal , it will drive a stepper motor the rotational direction is set to a fixed angle , referred to as " step angle ", which is fixed to the rotational angle of the step by step operation . The number of pulses can be controlled by controlling the amount of angular displacement , so as to achieve accurate positioning ; while the pulse frequency can be controlled by controlling the motor rotation speed and acceleration to achieve speed control purposes .1. basic introductionStepper motor is an induction motor, it works by using an electronic circuit .The DC power into power -sharing , multi-phase timing control current, this current is powered stepper motor , stepper motor to work properly, the stepper motor drive is powered -sharing , multi-phase timing controller .Although the stepper motor has been widely used, but the stepper motor does not like an ordinary DC motors, AC motors for use in routine under . It must be by a two- ring pulse signal , power driver circuit composed of the control system can be used. So make good use of a stepper motor , but not easy, it involves a lot of expertise in mechanical ,electrical , electronics and computers.Stepper motors as actuators , is one of the key products of mechatronics , widely used in a variety of automated control systems. With the development of microelectronics and computer technology, the growing demand for stepper motor , has applications in various fields of national economy .Stepper motor is an electrical pulse into the angular displacement of the actuator. Plainly speaking : When the stepper drive receives a pulse signal , it will drive a stepper motor to set the direction of rotation of a fixed angle ( ie, step angle ) . The number of pulses can be controlled by controlling the amount of angular displacement , so as to achieve accurate positioning ; while the pulse frequency can be controlled by controlling the motor rotation speed and acceleration to achieve speed control purposes .2. major categoriesThere are three main types of stepper motors in the structure : Reaction (Variable Reluctance, VR), permanent magnet (Permanent Magnet, PM) and hybrid (Hybrid Stepping, HS).Reaction: the stator windings , the rotor soft magnetic material. Simple structure, low cost , small step angle up to 1.2 °, but poor dynamic performance , low efficiency, heat a large , difficult to guarantee reliability .Permanent magnet : permanent magnet stepper motors with permanent magnet rotor material, the number of poles of the rotor and the stator of the same number of poles . Which is characterized by good dynamicperformance, output torque, this motor but poor accuracy , a large step angle (typically 7.5 ° or 15 °).Hybrid : a combination of hybrid stepping motors and permanent magnet reactive advantage of its multi-phase windings on the stator , the rotor permanent magnet material , the rotor and the stator teeth are a number of small steps to improve the accuracy of the moment . It features an output torque, good dynamic performance, step angle is small, but the structure is complex, the cost is relatively high.Press the stator windings to points , a total of two-phase , three-phase and five equal series. Most popular is the two-phase hybrid stepping motor , accounting for more than 97 % market share , the reason is the high cost , coupled with good results after the breakdown of the drive. This kind of basic step angle of the motor 1.8 °/ step , half step back coupled with the drive to reduce the step angle of 0.9 °, coupled with sub-drive after its step angle can be broken up to 256 -fold (0.007 °/ micro step ) . Due to friction and manufacturing precision and other reasons , the actual control accuracy is slightly lower . Same stepper motors can be equipped with different segments of the drive to change the precision and effectiveness.3. selection methodStepper motor and drive selection methods :Determine how much torque is required : static torque stepper motor is to choose one of the main parameters. Load is large, requires the use of high torque motor. Indicators big moment , the motor appearance is also large.Determine motor speed : high speed requirements , should be selected phase current is larger , smaller inductor motors to increase power input. And select the drive when using higher supply voltages.Select motor installation specifications : as 57,86,110 , the main requirements for the moment .Determine the precision positioning requirements and vibration aspects of the case : to determine whether the required segments, the number of segments required .According to the motor current , supply voltage breakdown and select the drive .4. Basic PrinciplesWorksThe rotor is a permanent magnet motor typically , when a current flows through the stator windings , the stator winding generates a magnetic field vector . The rotating magnetic field to drive the rotor at an angle such that the magnetic field of the stator is consistent with a direction of the magnetic field of the rotor. When the stator magnetic field vector rotation angle. As the rotors turn a field angle . Each input an electrical pulse , the motor rotation angle forward. The number of pulses proportional to the angular displacement of the output and its input , the pulse frequency is proportional to the rotational speed . Change the order of the winding is energized , the motor will reverse. Therefore, the number of pulses can be used to control power-on sequence , frequency and motor windings to control each phase stepper motor rotation .Fever principleUsually see all kinds of motors , are all inside the core and windings . Windings resistance , power will produce loss , the loss is proportional to the square of the size of the resistance and current , and this is what we often say that the copper losses , if the current is not a standard DC or sine wave , but also produce harmonic losses ; core has hysteresis eddy current effect , in the alternating magnetic field will produce losses , its size and materials , current, frequency , voltage dependent , called iron loss. Copper and iron losses are manifested in the form of heat , thus affecting the efficiency of the motor . Stepper motors are generally pursue positioning accuracy and torque output , efficiency is relatively low, the current is generally relatively large, and the high harmonic components , the frequency of the alternating current with the speed of change, thus stepping motor widespread fever cases and situations than the general severe AC motor .5. major tectonicStepping motor is also called a stepper , which uses the principle of electromagnetic , mechanical energy is converted to electrical energy , People as early as the 1920s began to use this motor . As embedded systems ( such as printers, disk drives , toys, wipers, pager vibration , mechanical arm and video recorders , etc. ) of the increasingly popular use of the stepper motor also began surge. Whether in industrial, military , medical, automotive or entertainment industry , as long as a piece of the object needs to be moved from one location to another , the stepper motor will certainly come in handy. Stepper motors have many shapes and sizes, but regardless of how the shape and size , they can be classified into two categories : a variable reluctance stepper motors and permanent magnetstepper motors.A stepper motor is wound on the motor fixing part - the stator coils driven alveolar . Typically , a ring-shaped metal wire called a solenoid winding , and in the motor , the teeth around the winding wire is called the coil or phase .6. index termsStatic index terms1, number of phases : produce different on pole N, S magnetic excitation coil pairs. Common m said .2, Beats: cyclical changes in the magnetic field required to complete a number of pulses or conductive state with n, or refer to the motor turned a pitch angle required number of pulses to four-phase motor, for example , there are four ways with four -run shot that AB-BC-CD-DA-AB, four-phase eight-shot operation That way A-AB-B-BC-C-CD-D-DA-A. 3, step angle : corresponds to a pulse signal , the angular displacement of the rotor turn is repre sented by θ. θ = 360 degrees / ( number of rotor teeth * run shot ) to the conventional two , four-phase , the rotor teeth 50 teeth motor, for example . Four beats running step angle is θ = 360 degrees / ( 50 * 4 ) = 1.8 degrees ( commonly known as the full step ) , eight-shot operation step angle of θ = 360 degrees / ( 50 * 8 ) = 0.9 degrees ( commonly known as half-step ) .4, the detent torque : motor is not energized in the state itself locked rotor torque ( harmonics and mechanical error by the magnetic field caused by the tooth ) .5, static torque : motor at rated static electricity effect, the motor doesnot rotates when the motor shaft locking torque. This moment is a measure of the volume of the standard motor , regardless of the driving voltage and driving power supply. Although static torque is proportional to the electromagnetic excitation ampere-turns , and set the air gap between the rotor teeth related, but over the use of the air gap decreases , increasing the excitation ampere-turns to increase the static torque is not desirable, this will cause motor heating and mechanical noise.Dynamic Indicators term1,step angle accuracy: stepper motor turned every error between the actual value and the theoretical value of a step angle . Expressed as a percentage : error / step angle * 100 %. Different running different beats its value , when the four -run shot in the 5% ,eight shot should run less than 15 %.2, step : the number of steps the motor running operation does not mean that the theoretical number of steps . Called out of step .3, the offset angle: rotor stator teeth tooth axis shift axis angle , the motor is running there must be offset angle , angle error generated by the imbalance , driven by subdivision can not be solved .4, he maximum no-load starting frequency : motor in the form of a drive voltage and rated current, in the case without the load, the maximum frequency can directly start .5, the operating frequency of the maximum load : the motor in the form of a drive voltage and rated current, the maximum speed of the motor with no load frequency .6, running torque characteristics : Measured motor running undercertain test conditions the output torque versus frequency curve is called the running torque-frequency characteristic , which is the motor of many dynamic curve of the most important , but also the fundamental basis for the motor selection.Other features include inertia frequency characteristics, starting frequency characteristics. Once the motor is selected, the static torque of the motor is determined , and dynamic moment is not the case , the dynamic torque motor depends on the average current ( rather than static current ) motor is running , the average current , the greater the motor output torque that the motor frequency characteristics of the harder . For the average current, the drive voltage to maximize the use of small high-current inductor motor .7, the resonance point of the motor : stepper motor has a fixed resonance region , two , four-phase Induction resonance zone is generally between 180-250pps ( step angle of 1.8 degrees ) , or about 400pps ( step angle 0.9 degrees ) , the higher the motor drive voltage , motor current increases, the lighter the load , motor size smaller, the upward shift resonance region , and vice versa , so that the motor output torque is large , and the entire system without losing step noise reduction , general working point should shift more resonance region .8, motor reversing control : the timing of when the motor windings are energized for the forward , the timing is energized when AB-BC-CD-DA or () DA-CD-BC-AB or ( ) when inverted.7. features characteristicThe main features1, the general accuracy of the stepper motor step angle of 3-5 % , and does not accumulate.2, the appearance of the stepper motor maximum temperature allowed . First, make a stepper motor temperature magnetic motor demagnetization ,Resulting in the loss of torque down even further , so the maximum temperature of the motor should be allowed depending on the appearance of magnetic motor demagnetization points ; generally speaking, magnetic demagnetization points above 130 degrees Celsius , and some even as high as 200 degrees Celsius above , so the stepper motor surface temperature at 80-90 degrees Celsius completely normal .3, stepper motor torque will increase with the speed of decline .When the stepping motor rotates , the inductance of the motor windings of each phase will form a counter electromotive force ; the higher the frequency, the greater the back EMF . In its role, the motor with frequency ( or speed ) increases the phase current is reduced , resulting in decreased torque .4, the stepper motor can operate normally at low , but if more than a certain speed will not start , accompanied by howling.Stepper motor has a technical parameter : load starting frequency , ie stepper motor under no-load conditions to start the normal pulse frequency , if the pulse frequency is higher than this value, the motor does not start properly , you may lose steps or stall . Under a load , the starting frequency should be lower . If you want the motor to achieve high-speed rotation , the pulse frequency should speed up the process ,which starts at lower frequencies , and then rise to the hope that at a certain acceleration frequency ( motor speed rise from low speed ) . Stepper motor with its remarkable features in the era of digital manufacturing plays a significant purpose. Along with improving the different development of digital technology and the technology itself, stepper motor , stepper motors will be applied in more fields .Key FeaturesA stepping motor can be operated must be added before the drive , the drive signal is a pulse signal to be no pulse when the stepping motor is stationary, if the addition of a suitable pulse signal will at a certain angle ( called a step angle ) is rotated. Rotational speed and the pulse frequency is proportional to .2, phase stepper motor step angle of 7.5 degrees, 360 degrees around , you need to complete the 48 pulses .3, stepper motor with instant start and stop the rapid superior characteristics .4, change the order of the pulse , you can easily change the direction of rotation .Therefore , printers , plotters , robotics and other equipment to the stepper motor driven core .8. speed methodStepper motor pulse signal is converted to angular displacement or linear displacement .First, the overload is good. Its speed independent of load size , unlikeordinary motor when the load increase rate decline occurs when using the stepper motor speed and position , there are stringent requirements.The second is easy to control. Stepper motors are "steps" as a unit rotation , digital features more obvious .Third, the whole structure is simple . Traditional mechanical speed and position control structure is complicated , difficult to adjust after using stepper motors , which makes it simple and compact structure . Motor rotation speed is converted into a voltage , and passed as a feedback signal to the input terminal . Tacho is an auxiliary motor , the motor is installed at the end of the ordinary speed DC motor , the voltage generated by the motor speed feedback to the DC power supply, DC motor speed control to achieve the purpose .9. function module designThis module can be divided into the following three parts:· SCM system : control of stepper motors ;· Peripheral circuits : PIC microcontroller interface circuit and stepper motors ;· PIC procedure : Write SCM stepper electric power machine interface program to achieve output of the triangular wave signal.( 1 ) stepper motor and microcontroller interface .SCM is the excellent performance of the control processor, stepper motor control , interface components must have the following features.① voltage isolation .SCM work at 5V, while the stepper motor is working in dozens of V, or even higher. Once the voltage to the microcontroller series stepper motor , it will damage the microcontroller ; signals would interfere with chip stepper motor , the system may also lead to errors in the work , so the interface device must have isolation .② messaging functions.Interface components should be able to pass information to the microcontroller stepper motor control circuit generates control information needed work , corresponding to different ways of working, interface components should be able to produce a corresponding job control waveform.③ produce different frequencies required .To the stepping motor at different speeds to suit different purposes , interface components should produce different operating frequencies . ( 2 ) V oltage Isolation interface.Isolation voltage isolation interface dedicated to the low-pressure part of the microcontroller and the stepper motor drive circuit high-voltage part , to ensure that they work properly.V oltage pulse transformer isolation interface or optical isolator is basically the use of optical isolators. Microcontroller output signal can be sent directly to the TTL gate or base of the transistor , and then driven by the transistor optocoupler devices emitting diodes.Light -emitting diodes on the opto-coupler devices inside the photodiode , converted into electrical signals , go drive a stepper motor power amplifier circuit , current amplification interface is a stepper motoramplifier circuit preamplifier circuit . Its role is to optical isolator output signal current amplification in order to provide enough power amplifier circuit drive current .( 3 ) Work interface and frequency generator .MCU controlled stepper motor requires the input and output interfaces for controlling stepper motors using three I / 0 lines, this time, the microcontroller I / O port RA0, RAI, RA2 control three-phase stepping motor .10. advantages and defectsAdvantage1, the angle of rotation of the motor is proportional to the number of pulses ;2, when the motor is stopped with a maximum torque ( when winding excitation time ) ;3, the accuracy of each step in the three percent to five percent , but the error will not accumulate to the next step and thus a better position accuracy and repeatability movement ;4, excellent response from the stop and reverse ;5, since there is no brush , high reliability, and therefore the life of the motor depends only on bearing life ;6, only the response of the motor is determined by the digital input pulse , which can be open-loop control, which makes the structure of the motor can be relatively simple and cost control ;7, only the load can be connected directly to a very low speed synchronous rotation on the shaft of the motor ;8, since the speed is proportional to the pulse frequency , and thus a relatively wide speed range.Defect1, if not properly controlled prone resonance ;2, the high speed operation is difficult ;3, it is difficult to obtain a large torque ;4, there is no advantage, low energy efficiency in terms of volume and weight ;5, more than the load will destroy the synchronization , will be issued when the high speed vibration and noise .11. drive methodStepper motors can be connected directly to the power frequency AC or DC power source to work , but must use a dedicated stepper motor driver , which occurs by the pulse control unit , power drive unit , the protection unit and so on. Stepper motor drive unit with direct coupling , can also be interpreted as a stepper motor controller microprocessor power connector.12. drive requirements1, can provide rapid current rise and fall times ,Current waveform as close as possible to make a rectangle .With a cut-off period for the release of the current flow loop to reducethe back electromotive force at both ends of the windings and accelerate the current decay .2, has a high rhyme power and efficiency.Stepper motor driver , which is a pulse signal into the control system of the angular displacement of the stepper motor , or : a control signal for each pulse issued by the stepper motor drive of a step angle of rotation . That frequency is proportional to the speed of the stepper motor pulse signal. So to control the frequency pulse signal , the speed of the motor can be accurately ; controlled stepper pulse number , you can pinpoint the motor . There are a lot of stepper motor drive , power requirements should be based on the actual reasonable choice drive.13. Major ApplicationsSelect the stepper motorThere are step angle stepping motor ( related to the number of phases ) , static torque , and the current composition of the three elements .Once identified three elements , the stepper motor model has determined.1, step angle selectionStep motor angle accuracy depends on the load requirements , the minimum resolution of the load ( equivalent ) conversion to the motor shaft , the number of angles ( including gear ) for each equivalent motor should go. Step motor angle should be equal to or less than this angle. Step angle stepping motor on the market are generally 0.36 °/ 0.72 °( five-phase motors ) , 0.9 degrees / 1.8 degrees ( two , four-phase motor ) , 1.5 degrees / 3 degrees ( three-phase motors ) and so on.2, static moment of choiceDynamic torque stepper motor is difficult to determine all of a sudden , we tend to first determine the static torque of the motor. The choice is based on static torque load on the motor work, and the inertia of the load and the load can be divided into two kinds of friction load . Single inertia load and a single load is not present in friction . When direct start ( generally low ) when the two loads are to be considered , the main consideration inertial load during acceleration start, constant run into just consider friction loads. Under normal circumstances, the static torque should be 2-3 times the load of friction is good, static torque Once selected, the machine base and be able to determine the length of the motor down ( geometry ) .3, the current selectionLike static torque motors , due to the different current parameters , their operating characteristics vary greatly, can be based on torque-frequency characteristic curve , determine the motor current . Application note points1, the stepper motor used in low-speed situations --- rpm less than 1000 rpm , ( 0.9 degrees 6666PPS), preferably using 1000-3000PPS (0.9 degrees ) between , can make it work here through deceleration devices, At this high electrical efficiency, low noise ;2, the stepper motor is best not to use the state of the whole step , whole step when the state of vibration ;3, due to historical reasons, only a nominal voltage of 12V 12V motors , the voltage value other than the motor drive voltage V value, drive selectdriving voltage according to ( suggestions : 57BYG DC 24V-36V, 86BYG DC 50V, 110BYG using higher than the DC 80V), of course, in addition to 12 volts 12V constant voltage driver can also use other external power supply, but to consider the temperature rise ;4, the moment of inertia of the load should choose a large frame size motors ;5, when compared with the high-speed motor or high inertia loads , generally do not start working speed , and the use of up- speed gradually , without losing a step motor , two noise can be reduced while improving the positioning accuracy is stopped ;6, high-precision, through mechanical reduction should improve motor speed , or high number of sub-drive to solve, 5 -phase motor can also be used , but the prices of its entire system more expensive , less manufacturer , which is eliminated argument is the layman ;7, the vibration motor in the region should not , should be resolved by changing the voltage , current, or add some damping ;8, motor 600PPS (0.9 degrees ) following work should be low current , high inductance , low voltage to drive ;9, after the first election should follow the principle of the drive motor option .步进电机步进电机是将电脉冲信号转变为角位移或线位移的开环控制元步进电机件。
步进电机及其驱动系统简介中英文翻译
步进电机及其驱动系统简介中英文翻译Step characteristics for machine for angular displacement forentering the electrical engineering is first kind will give or getan electric shocking the pulse signal conversion cowgirl or line potential moving battery carry outing a piece, having the fast stopping, accurate step entering and directly accepting the arithmetic figure measuring, because of but got the extensive application.Such as in the drafting machine, print the machine and optical instrument inside, and all adopt the inside of a place control system for entering theelectrical engineering to positioning to paint the pen print head or optical prinipal, especially indrstry process the type control, and move to spread to feel the to can immediately attain the precision fixed position because of its precision and need not potential, and control the technique along with the calculator of continuously deveolp, applied to would be more and more extensive.Control and can is divided into the simple control sum the complicacyto control to motor two kind.The simple control points to proceedsto start to motor, the system move, positive and negative revolution and sequential plicacy the control point to the motor's revolving speed, screw angle, turning moment, tension, electric current etc. physics quantisty progress control.Control technique that thedevelopment that motor get force is in latest development achievement thatmicro-electronics technique, electric power electronics, spread to feel the the technique, automatic control the technique, tiny machine the application technique to wait.Exactly the advance of these techniques make the motor control the technique at near two 10-year insides change for turn overing the ground of day is take placed.Among them the motor's control division have already been controled by emulation gradually let locate to regard single flake machine as principle of microprocessor control, formation the mix control system of the arithmetic figure and emulation and the application of the pure arithmetic figure control system, combine control the direction to total amount word to quickly deveolp.The motor's drive part of power for using the piece experienced a few renewals1to change the on behalf, current switch speed sooner, more simple wholetype power piece of control the MOSFET become the main current with IGBT.Stepper motors have the following benefits:• Low cost• Ruggedness• Simplicity in construction• High reliability• No maintenance• Wide acceptance• No tweaking to stabilize• No feedback components are needed• They work in just about any environment• Inherently more failsafe than servo motors.There is virtually no conceivable failure within the stepper drive module that could cause the motor to run away. Stepper motors are simple to drive and control in an open-loop configuration. They onlyrequire fourleads. They provide excellent torque at low speeds, up to 5 timesthecontinuous torque of a brush motor of the same frame size or double thetorque of the equivalent brushless motor. This often eliminates the needfor a gearbox. A stepper-driven-system is inherently stiff, with knownlimits to the dynamic position error.Stepper Motor DisadvantagesStepper motors have the following disadvantages:• Res onance effects and relatively long settlingtimes• Rough performance at low speed unless amicrostep drive is used• Liability to undetected position loss as a result ofoperating open-loop• They consume current regardless of loadconditions and therefore tend to run hot• Losses at speed are relatively high and can causeexcessive heating, and they are frequently noisy(especially at high speeds).2• They can exhibit lag-lead oscillation, which isdifficult to damp. There is a limit to their availablesize, and positioning accuracy relies on themechanics (e.g., ballscrew accuracy). Many ofthese drawbacks can be overcome by the use ofa closed-loop control scheme.Note: The Compumotor Zeta Series minimizes orreduces many of these different stepper motor disadvantages.There are three main stepper motor types:• Permanent Magnet (P.M.) Motors• Variable Reluctance (V.R.) Motors• Hybrid MotorsWhen the motor is driven in its full-step mode, energizing two windings or “phases” at a time (see Fig. 1.8), the torque available oneach step will be the same (subject to very small variations in the motorand drive characteristics). In the half-step mode, we arealternatelyenergizing two phases and then only one as shown in Fig. 1.9. Assumingthe drive delivers the same winding current in each case, this will causegreater torque to be produced when there are two windings energized. Inother words, alternate steps will be strong and weak. This does not represent a major deterrent to motor performance—the available torqueis obviously limited by the weaker step, but there will be a significantimprovement in low-speed smoothness over the full-step mode.Applications in hazardous environmentsor in a vacuum may not be able to use a brushed motor. Either a stepper or a brushless motor is called for, depending on the demands of the load.Bear in mind that heat dissipation may be a problem in a vacuum when theloads are excessive.continuous duty applications suit the servo motor, and in fact astep motor should be avoided in such applications because the high-speed lossescan cause excessive motor heating.are the natural domain of the stepper due to its high torque at low speeds, good torque-to-inertia ratio and lack of commutation problems.The brushes of the DC motor can limit its potential for frequent starts,3stops and direction changes.continuous duty applications are appropriate to the step motor. At low speeds it is very efficient in terms of torque output relativeto bothsize and input power. Microstepping can be used to improve smoothness inlowspeed applications such as a metering pump drive for veryaccurate flowcontrol.Stepper motor is a stepper motor for precise electrical and mechanicalactuators, which are widely used in industrial machinery, digital control,for the system reliability, interoperability, maintainability, andcost-optimal, according to the control system functional requirements andControl system through the microcontroller memory, I/O interface, interrupt, keyboard, LED display of the expansion of the annular distributor stepping motor, drive and protection circuit, man-machineinterface circuit, interrupt system and reset circuit, a single voltagedrive circuit, etc.designed to achieve a four-phase stepper motor rotating, and emergency stop functions. To achieve the steppingmotorsystem in NC Machine Tools, system design, two external interrupts,inorder to achieve within a certain period of time stepper motor repeatedReversible function, ie, the turret CNC automatic feed movement.With thecontinuous development of single chip microcomputer, microcontroller inhousehold electronic products widely applied, since the since the earlysixties, the stepper motor applications are greatly enhanced. People useit to drive the clock and other instruments with pointers, printers,plotters, disk CD-ROM drive, a variety of automatic control valves, various tools, as well as robots and other mechanical devices. In addition,as the acIn addition, as the actuator, stepper motor is one ofmechanical and electrical integration of the key products are widely usedin a variety of automatic control systems, microelectronics and computertechnology with the development of its requirements with the Japanese fearof growing in all the field of application of the national economy has. Stepper motor digital control system of electromechanicalactuators commonly used, due to its high precision, small size, flexibleto control, so the smart meter and position control has been widely usedin large-scale integrated circuits technology development, and SCM The4increasing popularity of design features, the lowest price of the steppermotor control driver provides advanced technology and adequate resources.步进电机是一种将电脉冲信号转换成相应的角位移或线位移的机电执行元件,具有快速启停、精确步进以及直接接受数字量的特点,因而得到了广泛的应用。
电机行业常用的中英文对照
电机行业常用的中英文对照 induction machine 感应式电机horseshoe magnet 马蹄形磁铁magnetic field 磁场eddy current 涡流right-hand rule 右手定则left-hand rule 左手定则slip 转差率induction motor 感应电动机rotating magnetic field 旋转磁场winding 绕组stator 定子rotor 转子induced current 感生电流time-phase 时间相位exciting voltage 励磁电压slot 槽lamination 叠片laminated core 叠片铁芯short-circuiting ring 短路环squirrel cage 鼠笼rotor core 转子铁芯cast-aluminum rotor 铸铝转子bronze 青铜horsepower 马力random-wound 散绕insulation 绝缘ac motor 交流环电动机end ring 端环alloy 合金coil winding 线圈绕组form-wound 模绕performance characteristic 工作特性 frequency 频率revolutions per minute 转/分motoring 电动机驱动generating 发电per-unit value 标么值breakdown torque 极限转矩breakaway force 起步阻力overhauling 检修wind-driven generator 风动发电机revolutions per second 转/秒number of poles 极数speed-torque curve 转速力矩特性曲线 plugging 反向制动synchronous speed 同步转速percentage 百分数locked-rotor torque 锁定转子转矩full-load torque 满载转矩prime mover 原动机inrush current 涌流magnetizing reacance 磁化电抗line-to-neutral 线与中性点间的staor winding 定子绕组leakage reactance 漏磁电抗no-load 空载full load 满载Polyphase 多相(的)iron-loss 铁损complex impedance 复数阻抗rotor resistance 转子电阻leakage flux 漏磁通locked-rotor 锁定转子chopper circuit 斩波电路separately excited 他励的compounded 复励dc motor 直流电动机de machine 直流电机speed regulation 速度调节shunt 并励series 串励armature circuit 电枢电路optical fiber 光纤interoffice 局间的waveguide 波导波导管bandwidth 带宽light emitting diode 发光二极管 silica 硅石二氧化硅regeneration 再生, 后反馈放大 coaxial 共轴的,同轴的high-performance 高性能的carrier 载波mature 成熟的Single Side Band(SSB) 单边带coupling capacitor 结合电容propagate 传导传播modulator 调制器demodulator 解调器line trap 限波器shunt 分路器Amplitude Modulation(AM 调幅Frequency Shift Keying(FSK) 移频键控tuner 调谐器attenuate 衰减incident 入射的two-way configuration 二线制generator voltage 发电机电压dc generator 直流发电机polyphase rectifier 多相整流器boost 增压time constant 时间常数forward transfer function 正向传递函数error signal 误差信号regulator 调节器stabilizing transformer 稳定变压器time delay 延时direct axis transient time constant 直轴瞬变时间常数 transient response 瞬态响应solid state 固体buck 补偿operational calculus 算符演算gain 增益pole 极点feedback signal 反馈信号dynamic response 动态响应voltage control system 电压控制系统mismatch 失配error detector 误差检测器excitation system 励磁系统field current 励磁电流transistor 晶体管high-gain 高增益boost-buck 升压去磁feedback system 反馈系统reactive power 无功功率feedback loop 反馈回路automatic Voltage regulator(AVR)自动电压调整器 reference Voltage 基准电压magnetic amplifier 磁放大器amplidyne 微场扩流发电机self-exciting 自励的limiter 限幅器manual control 手动控制block diagram 方框图linear zone 线性区potential transformer 电压互感器 stabilization network 稳定网络stabilizer 稳定器air-gap flux 气隙磁通saturation effect 饱和效应saturation curve 饱和曲线flux linkage 磁链per unit value 标么值shunt field 并励磁场magnetic circuit 磁路load-saturation curve 负载饱和曲线 air-gap line 气隙磁化线polyphase rectifier 多相整流器circuit components 电路元件circuit parameters 电路参数electrical device 电气设备electric energy 电能primary cell 原生电池energy converter 电能转换器conductor 导体heating appliance 电热器direct-current 直流time invariant 时不变的self-inductor 自感mutual-inductor 互感the dielectric 电介质storage battery 蓄电池e.m.f = electromotive fore 电动势unidirectional current 单方向性电流circuit diagram 电路图load characteristic 负载特性terminal voltage 端电压external characteristic 外特性conductance 电导volt-ampere characteristics 伏安特性carbon-filament lamp 碳丝灯泡ideal source 理想电源internal resistance 内阻active (passive) circuit elements 有(无)源电路元件leakage current 漏电流circuit branch 支路P.D. = potential drop 电压降potential distribution 电位分布r.m.s values = root mean square values 均方根值 effective values 有效值steady direct current 恒稳直流电sinusoidal time function 正弦时间函数complex number 复数Cartesian coordinates 笛卡儿坐标系modulus 模real part 实部imaginary part 虚部displacement current 位移电流trigonometric transformations 瞬时值epoch angle 初相角phase displacement 相位差signal amplifier 小信号放大器mid-frequency band 中频带bipolar junction transistor (BJT) 双极性晶体管 field effect transistor (FET) 场效应管electrode 电极电焊条polarity 极性gain 增益isolation 隔离分离绝缘隔振emitter 发射管放射器发射极collector 集电极base 基极self-bias resistor 自偏置电阻triangular symbol 三角符号phase reversal 反相infinite voltage gain 无穷大电压增益feedback component 反馈元件differentiation 微分integration 积分下限impedance 阻抗fidelity 保真度summing circuit 总和线路反馈系统中的比较环节 Oscillation 振荡inverse 倒数admittance 导纳transformer 变压器turns ratio 变比匝比ampere-turns 安匝(数)mutual flux 交互(主)磁通vector equation 向(相)量方程power frequency 工频capacitance effect 电容效应induction machine 感应电机shunt excited 并励series excited 串励separately excited 他励self excited 自励field winding 磁场绕组励磁绕组speed-torque characteristic 速度转矩特性dynamic-state operation 动态运行salient poles 凸极excited by 励磁field coils 励磁线圈air-gap flux distribution 气隙磁通分布direct axis 直轴armature coil 电枢线圈rotating commutator 旋转(整流子)换向器commutator-brush combination 换向器-电刷总线 mechanical rectifier 机械式整流器Geometrical position 几何位置magnetic torque 电磁转矩spatial waveform 空间波形sinusoidal density wave 正弦磁密度external armature circuit 电枢外电路instantaneous electric power 瞬时电功率instantaneous mechanical power 瞬时机械功率 effects of saturation 饱和效应reluctance 磁阻power amplifier 功率放大器compound generator 复励发电机rheostat 变阻器self excitation process 自励过程commutation condition 换向状况cumulatively compounded motor 积复励电动机 operating condition 运行状态equivalent T circuit T型等值电路rotor (stator) winding 转子(定子绕组)winding loss 绕组(铜)损耗prime motor 原动机active component 有功分量reactive component 无功分量electromagnetic torque 电磁转矩retarding torque 制动转矩inductive component 感性(无功)分量abscissa axis 横坐标induction generator 感应发电机synchronous generator 同步发电机automatic station 无人值守电站hydropower station 水电站process of self excitation 自励过程auxiliary motor 辅助电动机technical specifications 技术条件voltage across the terminals 端电压steady state condition 瞬态暂态reactive in respect to 相对….呈感性active in respect to 相对….呈阻性synchronous condenser 同步进相(调相)机 coincide in phase with 与….同相synchronous reactance 同步电抗algebraic 代数的algorithmic 算法的biphase 双相的bilateral circuit 双向电路bimotored 双马达的corridor 通路shunt displacement current 旁路位移电流leakage 泄漏lightning shielding 避雷harmonic 谐波的motor transport facilities 汽车运输设备motor transport maintenance 汽车运输保养motor treak 电动机驱动的断续器motor trend 汽车的发展趋向motor tricycle 三轮摩托车motor trolley 轨道摩托车motor truck 运货汽车; 载重卡车motor truck road 汽车干道motor truck supply 载重汽车补给motor truck terminal 载重汽车站motor tune-up 发动机调整motor turning 汽车转向motor type 电动机型式motor type insulator 电动机型绝缘子motor type relay 电动机式继电器; 电动机型继电器; 电动继电器motor tyre 汽车轮胎motor tyre casing 汽车轮胎外胎; 汽车外胎motor uniselector 机动选择器motor unit 电动机组; 运动单位motor unit potential 运动单位电势; 运动单位电位motor valve 马达阀motor vehicle 动力车; 汽车motor vehicle equipment 汽车装备motor vehicle passenger insurance 汽车乘客险motor vehicle third party insurance 汽车第三者责任保险motor vehicles in use 汽车使用数motor vessel 内燃机船motor wagon 电动货车motor winch 电动绞车; 机动绞盘motor windlass 电动起锚机motor wiring 电动机布线motor with combined ventilation 混合通风式电动机motor with compound characteristic 复励特性电动机motor with reciprocating movement 反转电动机; 往复运动电动机motor with self excitation 自激电动机motor with series characteristic 串励特性电动机motor with shunt characteristic 并励特性电动机motor with water cooling 水冷式电动机motor works 汽车制造厂motor wrench pipe dog 管子钳motor(vertical) 立装电动机motor-armature 电动机电枢motor-blower 电动鼓风机motor-booster 电动升压机motor-circuit switch 电动机馈线开关motor-compression refrigerator 电动机压缩式冰箱motor-converter 电动变流机motor-dom 汽车界; 汽车行业motor-drive lathe 电动车床motor-drive shaft and pinion 电动机传动轴和小齿轮motor-driven 电动的; 电动机拖动的; 电机驱动的motor-driven blower 电动鼓风机motor-driven cable-winch 电动电缆绞车motor-driven feed pump 电动给水泵motor-driven grader 机动平地机motor-driven interrupter 电动断续器motor-driven maize sheller 机动玉米脱粒机motor-driven pump 电动泵motor-driven seed cleaner 电机驱动种子清选机motor-driven starter 电动起动器motor-driven switch 电动机驱动开关motor-driven switch-group 机动组合开关motor-driven valve 电动机拖动阀motor-driven welding machine 电动旋转式焊机motor-field 电机磁场motor-field control 电动机磁场控制motor-field failure relay 电动机磁场故障继电器motor-generator arc welder 电动发电弧焊机motor-generator locomotive 电动发电机机车motor-generator set 整流机motor-generator welder 电动发电电焊机motor-generator welding unit 电动直流发电焊接设备motor-in-wheel 车轮电动机motor-mount pump 电动泵; 马达泵motor-mounted bicycle 机动脚踏车motor-oil 电动机润滑油motor-operated 电动机带动的motor-operated cam type flash welder 电动凸轮式闪光焊机motor-operated horn 电动喇叭motor-operated potentiometer 电动机操作的电位器motor-operated rheostat 电动操作变阻器motor-operated shutter 机动阀门motor-operated switch 电动断路器; 电动开关motor-operated valve 电动阀motor-operated welder 电动加压焊机motor-output 电动机出力motor-pumped well 机井motor-selector (MS) 电动选择器motor-show 汽车展览motor-torque generator 一种同步驱动发电机motor-trolley 轨道车motor-truck oscillator 电动机调谐振荡器motor-vehicle accident 汽车事故motor-vehicle chassis 汽车底盘motor-winch 电动绞车motoralternator 电动机发电机组motorbi-cycle 摩托车motorbicycle lead-acid storage battery 摩托车用铅酸蓄电池motorbike 机器脚踏车motorboat 汽艇motorboating 汽艇声; 低声频振荡motorbus 大型客车; 公共汽车motorcar 电动车; 小汽车motorcar brake 自动车闸motorcar bulb 摩托车灯泡motorcar fitter 汽车修配工motorcar interference 汽车发动机干扰; 汽车干扰motorcar jack 汽车千斤顶motorcar set 汽车无线电设备motorcycle 摩托车; 机器脚踏车motorcycle accessories 摩托车配件motorcycle alarm 摩托车防盗器motorcycle battery 摩托车电池motorcycle carburetor 摩托车化油器motorcycle chain 摩托车链条motorcycle engine 摩托车发动机motorcycle gloves 摩托手套motorcycle helmet 摩托车头盔motorcycle insurance 摩托车保险motorcycle jacket 摩托茄克motorcycle oil 摩托车油motorcycle oil pump 摩托车机油泵; 摩托车润滑油泵motorcycle petrol switch 摩托车汽油开关motorcycle radio 摩托车无线电设备motorcycle sidecar 机器脚踏车边车motorcycle speedometer 摩托车里程速度表motorcycle tyre 摩托车轮胎motorcycle wheel-rim 摩托车轮辋motorcycle-racing arena 摩托车比赛场motordrome 汽车场; 汽车试车场motordynamo 电动发电机; 电动机发电机组motorette 绝缘寿命试验模型; 绝缘寿命试验模型motorgenerator set ( M. G. set) 电动发电机组motorgrader 自动平路机motorgraphic 描记运动的motorial compensation 运动性代偿motorial inhibition 运动抑制motoricity 运动力motoring friction 空转摩擦力motoring ring test 带动试验motoring run 发动机试运转motoring test 空转试验motoring torque 运动力矩motorised roll 电机传动辊motorist 汽车驾驶员motorization 摩托化ized (motorised) 装有发动机的motorized and mechanized troops 摩托化机械化部队motorized antitank weapons 摩托化防坦克武器motorized artillery 摩托化炮兵motorized caravan 敞篷汽车motorized cart 自行装置motorized copying camera 电动复制照相机motorized detachment 摩托化分遣队motorized engineer regiment 摩托化工程兵团motorized grader 机动平地机motorized knapsack 背负式机动喷雾器motorized knapsack mistblower 背负式机动鼓风喷雾器motorized non-return valve 电动止回阀motorized pan and tilt head 马达驱动的云台motorized panning head 马达驱动的摇头motorized ramp 自动梯motorized reconnaissance 摩托化侦察motorized reducer 带电动机的减速器; 带电动机减速器motorized road grader 自动平地机motorized shop truck 摩托化修理车motorized snowplow 摩托化扫雪机motorized speed reducer 电动减速器motorized tar spreader 自动式喷洒沥青机motorized transport 摩托化运输motorized traverser dolly 电动旋转移动台车motorized tuning control 电动机驱动的调谐系统motorized valve 电动阀motorized wheel drive 马达轮驱动motorized zoom lens 马达驱动的可变焦距镜头motorlaunch 汽艇motorless 无动力的motorlorry 卡车Motorloy (一种汽油添加剂的商品名) 摩托乐意motormaker 电机厂motormeter 运动力计; 运动能力计; 汽车仪表motorpathy 运动疗法; 体育疗法; 肌动疗法motorplane 动力飞机motorpump 马达泵; 电动泵; 机动泵motorr bicycle oil 摩托车油motors 汽车公司证券motorscootor 小型机车motorsensory cortex 运动感觉皮层motorship 内燃机船motorshipengine 轮机motorstarting reactor 发动机起动反应器motortherapy 运动疗法motortilter (dumper car,dumper) 自动倾卸汽车motortruck (automotive truck) 载货汽车motorway 汽车道; 汽车路; 快车道; 机动车行道motor-driven control valve 电动机拖动控制阀movable brush type polyphase series motor 活动电刷式多相串激电动机moving coil type torque motor 动圈式转矩马达multi-speed motor 多速电动机multifrequency motor-generator 多频电动发电机multiloop motor 多回路电动机multiphase motor 多相电动机multiple-cage motor 多鼠笼电动机multiple-motor 多电动机multiple-motor unit 多发动机装置multiple-speed motor 多速电动机multispeed motor 多速电动机myotonia motor neuron 肌紧张运动神经元nervus motorius 运动神经neutralized series motor 补偿串励电动机noiseless motor 无噪声电动机non-excited synchronous motor 反应式同步电动机non-regenerative compound motor 非再生复激电动机non-reversing motor 不反转马达non-standard motor 非标准型电机non-synchronous motor 非同步电动机; 异步电动机nonventilated motor 自冷电动机nose suspended motor 鼻式悬挂电机nuclei motorii nervi trigemini 三叉神经运动核number of motors 电机数量obliquely slotted motor 斜槽式电动机off-road motor transport equipment 越野汽车运输装备oil hydraulic motor 液压马达oil motor 油马达; 液压电动机; 液压发动机oil pump motor 油泵电动机oil type servo-motor 油压式伺服电动机oil-immersed torque motor 湿式力矩马达oilhydraulic motor 液压马达one motor traveling crane 单马达移动吊车one-cylinder motor 单缸发动机one-motor travel(1)ing crane 单马达吊车one-seat motorcycle 单座摩托车open general-purpose motor 敞开式通用电动机open motor 敞开式电动机; 开敞型电动机open type electric motor 敞开式电动机open type induction motor 敞开式感应电动机operating motor 操作电动机; 执行电动机operational motor movement 作战汽车运送orbit maneuver motor 变轨发动机orbit motor 摆线转子马达orienting thrust motor 定向推力发动机oscillating armature motor 振动电枢式电动机oscillating motor 摇动马达oscillatory motor 摆动式液压马达outboard motor 外置马达; 外装电动机; 舷外发动机; 舷外挂机; 操舟机outdoor motor 室外型电动机; 户外型电动机; 露天电动机overhung-type motor 悬装式电动机pancake motor 短轴型电动机; 扁平型电动机paper feed motor 输纸马达paraffin motor 石蜡发动机parallel connection of the motors 电动机并联法pen motor 记录笔电动机peripheral motor neuron 周围运动神经元perma-split capacity motor 固定分相的单相电容式电动机permanent-capacitor motor 永久电容器式电动机permanent-magnet stepper motor 永磁步进电动机permanent-split capacitor motor 固定分相电容器式电动机permasyn motor 永磁同步电动机permissible motor 密闭型电动机; 防爆电动机; 安全电动机petrol motor 汽油发动机; 汽油机petrol motor car 汽油机汽车petrol motor roller 汽油压路机petroleum motor oil 石油车用润滑油Petter motor oil test 培特发动机润滑油试验phase-wound motor 相绕式电动机phonic motor 蜂音电动机physical motor pool 汽车集中调度场pilot motor 辅导电动机; 辅助电动机; 伺服电动机pilot pressure pump motor 辅助压力泵马达pipe-ventilated motor 管道通风电动机piston motor 活塞液压马达pivoted motor 悬吊翻转电动机pivoting motor 铰链吊挂式发动机planar motor 平面电动机planar stator motor 平面定子电动机plunger motor 柱塞式液压电动机; 柱塞液动机pneumatic motor 风动马达; 气动电动机; 气力马达pole change motor 换极电动机pole changing motor 变极电动机pole-change motor starter 马达变极启动器pole-changing motor 变极式感应电动机poly-change speed motor 多速电动机polypase series commutator motor 多相串励换向器电动机polyphase asynchronous motor 多相异步电动机polyphase commutator motor 多相换向器电动机polyphase compound commutator motor 多相复励换向器电动机polyphase induction motor 多相感应电动机polyphase motor 多相电动机polyphase series commutator motor 多相串激换向器电动机polyphase series motor 多相串激电动机polyphase shunt commutator motor 多相并激换向器电动机; 多相并励换相器电动机polyphase shunt motor 多相并激电动机; 多相并励电动机polypole induction motor 多极感应电动机pony motor 小型电动机; 辅助电动机positive displacement hydraulic motor 容积式液压马达positive displacement motor 容积式液压马达; 正排量电动机positive-displacement motor 容积式液压电动机power of motor 电动机功率; 电机功率power selsyn motor 电力自动同步电动机; 动力自动同步机power-control motor 动力控制电动机premium motor fuel 高级车用汽油premium motor oil 高级车用机油; 高级车用汽油; 优质发动机油pressure combustion motor fuel 压燃式发动机燃料pressurized motor 充高压气体的密封电动机pressurized-enclosure motor 增压防爆型电动机primary motor 主电动机prime motor 原动机print motor 微电机print(ed) motor 印刷电动机printed motor 印刷式电动机propelling motor 推进发动机proportioning motor 比例电动机propulsion motor 推进电动机protected motor 防护式电动机pulley motor 电动机皮带轮pulling motor 牵引电机pulling motor speed control 牵引电机速度控制pulsating current motor 脉动电流电动机pulsating motor 往复运动电动机pulse DC motor 脉冲式直流电动机pulse motor 脉冲电动机pulse-jet motor 脉动喷气发动机pump and motor fluid ports 泵和液压马达间的液流阀pump motor 泵的电动机; 泵用电动机push-type motor grader 推板式平路机quadruple screw motor ship 四螺旋桨船quiet motor 低噪声电动机; 低噪音电动机; 无噪声电动机quieter motor 无噪声马达radix motoria 运动根radix ventralis motoria 腹侧运动根rail motor car 铁道机动车rail-motor 铁路公路联运railroad motor car 铁道机动车railway motor 铁路用电动机railway motor car 内燃机车rational vane hydraulic motor 定量叶片式液压马达reaction hysteresis synchronous motor 反应式磁滞同步电动机reaction motor 反应电动机; 反应式电动机; 反应式发动机; 反作用电动机; 反作用式电动机; 反作用式发动机; 喷气发动机reaction stepping motor 反应式步进电机reactive step motor 反应式步进电机reactor start motor 电抗起动电机; 电抗线圈起动电动机reactor-start motor 电抗线圈起动式电动机reaping attachment for motormower 动力割草机的谷物收割附加装置reciprocable motor 往复运动电动机recorder motor 记录器电动机rectifier-driven motor 整流器馈电的电动机rectilinear screw-thread reluctance motor 直线螺纹磁阻电动机reel motor 卷带电动机; 卷带电动机; 带盘电动机; 磁带盘电机refrigerant gas for cooling motor 冷却电动机用冷煤气refrigerator compressor motor 冰箱压缩机电机regenerative motor 再生发动机; 再生冷却式液体火箭发动机regenerative rocket motor 再生式火箭发动机regular motor oil 正规的车用机油regulating motor 调节电动机regulation of motor 电动机调整reluctance motor 磁阻电动机; 反应式同步电动机rent motor 三槽板间的面石repeating motor 步进电机repulsion and induction type motor 推斥感应式电动机repulsion and induction type single phase motor 推斥感应型单相电动机repulsion induction motor 推斥感应型电动机repulsion motor 推斥电动机; 推斥式电动机repulsion type motor 推斥型电动机repulsion-induction motor 推斥感应电动机repulsion-start induction motor 推斥起动感应电动机resistance-start motor 电阻起动电动机; 电阻起动电机reversible generator motor 可逆式发电电动机reversible motor 可逆电动机reversing motor 双向电动机; 双向旋转电动机; 双向旋转马达reversing rotation of motors 改变电动机的旋转方向revolving field type motor 转场式电动机rewinding motor 倒带电机; 重绕电动机rib-cooled motor 散热肋冷却型电动机ribbed motor 肋片型电动机; 散热片型电动机Richter motor 里克特电动机Rigg motor 里格径向柱塞液压电动机ring motor 环形电动机ripple current motor 脉动电动机; 脉动电流电动机rocket motor 火箭发动机rocket motor assembly 火箭发动机组rocket motor case 火箭发动机体rocket motor dynamics 火箭发动机动力学rocket motor injector 火箭发动机喷嘴roll motor 辊道电动机rolling mill motor 轧钢电动机rolling vane motor 旋转式叶片电动机rotary abutment motor 旋转隔板电动机; 旋转隔板马达rotary field motor 旋转磁场电动机rotary fixed displacement motor 旋转式固定排量发动机rotary hydraulic motor 旋转式液压马达rotary motor 回转马达rotary motor pump 回转式马达泵rotary piston hydraulic motor 旋转柱塞液压马达rotary stepping motor 旋转式步进电动机rotary vane motor 转翼式液压马达rotating-armature motor 转枢式电动机rotor feed type motor 转子馈电式电动机rotor feed type polyphase shunt motor 转子馈电式多相并激电动机rotor motor 转子式发动机round body motor 圆机壳电动机round frame motor(无突出轴承) 圆机壳电动机run motor 运转电动机salient pole synchronous induction motor 凸极式同步感应电动机scanning motor 扫描电动机Schmidt motor 施密特活塞液压电动机Schrage motor 施拉盖电动机screen coil motor 屏蔽线圈电动机screw for motor starter 马达起动器螺钉screw motor 螺杆马达screwdown motor 轧钢机用电动机sealed chart-drive motor 密封式记录纸驱动电动机segmented secondary reluctance motor 次级分段的磁阻电动机self start synchronous motor 自动起动同步电动机self(-)compensated motor 自补偿电动机self-contained motor drive 单独电动机传动self-drive motor 自起动电动机self-excited motor 自励电动机self-oscillating linear induction motor 自振荡直线感应电机self-propelled motor atomizer 自走式动力喷雾机self-start motor 自起动电动机self-start synchronous motor 自起动同步电动机self-starting motor 自起动电动机self-starting synchronous motor 自起动同步电动机self-synchronous motor 自同步电动机; 自同步机self-ventilated motor 自然通风电动机; 自然通风式电动机selsyn motor 自动同步电动机; 自同步电动机selsyn motor impulse clock 同步式电钟selsyn-drive electric motor 自整角机驱动电动机selsyn-type electrical motor 自整角电动机semi enclosed type motor 半封闭式电动机semi-infinite motor 半无限长电动机semi-motor 往复旋转液压油缸semienclosed motor 半封闭式电动机semiprotected motor 半防护型电动机sensori-motor phase 感觉动作时相separate electrical motor 单独电机separate excited motor 分激电动机separated excitation D.C. motor 分激直流电机separately excited motor 他励电动机series commutator motor 串励换向器电动机series conduction motor 单相串励换向器电动机; 交流串励换向器电动机series motor 串激电动机; 串励电动机series parallel motor 串并激电动机; 串并联电动机series wound motor 串绕电动机series-characteristic motor 串激特性电动机; 反速电动机series-repulsion motor 串激推斥电动机; 串联推斥电动机series-wound motor 串激电动机; 串励电动机servohydraulic rotary motor 液压伺服转子马达shaded-pole motor 罩极电动机shaft-drive motorcycle 轴动机器脚踏车shear motor 剪切机电动机shell-type motor 封闭型电动机shielded-pole motor 屏蔽极电动机shipboard-type motor 船用电动机short-hout motor 短期工作电动机short-period motor 短期工作发动机shunt motor 并激电动机; 并励电动机; 并绕电动机shunt-conduction motor 并激整流式交流电动机shunt-wound motor 并激电动机side drive motor mower 侧驱式动力割草机silage motor chain saw 切青贮料用的链锯silent motor 无噪声电动机simple selsyn motor system 简化自动同步机方式simplex motor 单工电动机; 同步感应电动机simulating motor 模拟电动机sine motor 正弦电动机; 正弦马达single cylinder motor 单汽缸发动机single cylinder two-stroke motor 单缸二冲程发动机single fed repulsion motor 单馈推斥式电动机single motor 单电动机; 单发动机single motor car 单电动机车single motor equipment 单发动机装置single phase commutator motor 单相整流子式电动机single phase selsyn motor 单相自动同步电动机single phase series commutator motor 单向串励换向器电动机single rail motor crab 单轨电动起重绞车single sided linear induction motor 单边直线感应电动机single speed motor 单速电动机single-phase capacitor operation asyn. motor 单相电容运转异步电动机single-phase capacitor starting induction motor 单相电容起动感应电动机single-phase clutch motor 单相离合器电动机single-phase commutator induction motor 单相整流子感应电动机single-phase commutator motor 单相换向器电动机; 单相整流电动机single-phase compound motor 单相复绕电动机single-phase condenser motor 单相电容电动机single-phase double-speed motor 单相双速电动机single-phase induction motor 单相感应电动机; 单向感应电动机single-phase motor 单相电动机single-phase selsyn. motor 单相自同步电动机single-phase series commutator motor 单相串激换向器电动机; 单相串激整流子电动机; 单相串励换向器电动机single-phase series motor 单相串激电动机; 单相串励电动机; 单相串联电动机single-phase shunt commutator motor 单相并励换向器电动机single-phase shunt motor 单相并激电动机; 单相并联电动机single-phase single-speed motor 单相单速电动机single-phase speed regulating motor 单相调速电机single-phase synchronous motor 单相同步电动机single-phase two-speed motor 单相双速电动机single-winding multispeed motor 单绕多速电动机skeleton(-type) motor 开敞型电动机slave motor 随动电动机slewing motor 回转电动机sliding-sleeve motor 滑阀配气发动机sliding-vane motor 叶片电动机; 叶片马达slip of induction motor 异步电动机的转差率slip ring motor 滑环式电动机slip-ring induction motor 滑环式感应电动机slip-ring motor 滑环电动机slip-ring type induction motor 滑环式感应电动机slow-speed motor 低速电动机small single-phase induction motor 小型单相感应电动机small size motor 小电动机small type motor 小型电动机small-capacity motor-driven thresher 电动小型脱谷机small-power motor 小功率电动机solo type motor cycle 单座式机器脚踏车somatic motor column 体壁运动柱somatic motor fiber 体壁运动纤维sound-proof motor 声处理的马达spare motor 备用电动机special (type) motor 特殊电动机special-duty motor 特殊工作制电动机; 特用电动机special-purpose motor 特殊功用电动机specific motor retardation 特殊运动迟缓speech motor hallucination 言语运动性幻觉speed control servo-motor 调速伺服电动机speed measuring motor 测速电机speed of motor 自动机转速; 自机转速speed of rotation of motor 电动机转速speed regulating motor 调速电动机; 调速伺服电动机speed-changer motor 同步器电动机spheric motor 球形电动机spin motor 旋转发动机。
步进电机 英文翻译.
郑州航空工业管理学院英文翻译2014 届电气工程及其自动化专业班级姓名学号指导教师职称二О一四年 2 月22 日Stepper motorStepper motor is the electrical pulse signal into angular displacement or linear displacement of an open loop stepper motor control element pieces . In the case of non- overloading , motor speed , stopped position depends only on the number of pulse frequency and pulse signals , which are not affected by changes in load , when stepper drive receives a pulse signal , it will drive a stepper motor the rotational direction is set to a fixed angle , referred to as " step angle ", which is fixed to the rotational angle of the step by step operation . The number of pulses can be controlled by controlling the amount of angular displacement , so as to achieve accurate positioning ; while the pulse frequency can be controlled by controlling the motor rotation speed and acceleration to achieve speed control purposes .1. basic introductionStepper motor is an induction motor, it works by using an electronic circuit .The DC power into power -sharing , multi-phase timing control current, this current is powered stepper motor , stepper motor to work properly, the stepper motor drive is powered -sharing , multi-phase timing controller .Although the stepper motor has been widely used, but the stepper motor does not like an ordinary DC motors, AC motors for use in routine under . It must be by a two- ring pulse signal , power driver circuit composed of the control system can be used. So make good use of a stepper motor , but not easy, it involves a lot of expertise in mechanical ,electrical , electronics and computers.Stepper motors as actuators , is one of the key products of mechatronics , widely used in a variety of automated control systems. With the development of microelectronics and computer technology, the growing demand for stepper motor , has applications in various fields of national economy .Stepper motor is an electrical pulse into the angular displacement of the actuator. Plainly speaking : When the stepper drive receives a pulse signal , it will drive a stepper motor to set the direction of rotation of a fixed angle ( ie, step angle . The number of pulses can be controlled by controlling the amount of angular displacement , so as to achieve accurate positioning ; while the pulse frequency can be controlled by controlling the motor rotation speed and acceleration to achieve speed control purposes .2. major categoriesThere are three main types of stepper motors in the structure : Reaction (Variable Reluctance, VR, permanent magnet (Permanent Magnet, PM and hybrid (Hybrid Stepping, HS.Reaction: the stator windings , the rotor soft magnetic material. Simple structure, low cost , small step angle up to 1.2 °, but poor dynamic performance , low efficiency, heat a large , difficult to guarantee reliability .Permanent magnet : permanent magnet stepper motors with permanent magnet rotor material, the number of poles of the rotor and the stator of the same number of poles . Which is characterized by good dynamicperformance, output torque, this motor but poor accuracy , a large step angle (typically 7.5 ° or 15 °.Hybrid : a combination of hybrid stepping motors and permanent magnet reactive advantage of its multi-phase windings on the stator , the rotor permanent magnet material , the rotor and the stator teeth are a number of small steps to improve the accuracy of the moment . It features an output torque, good dynamic performance, step angle is small, but the structure is complex, the cost is relatively high.Press the stator windings to points , a total of two-phase , three-phase and five equal series. Most popular is the two-phase hybrid stepping motor , accounting for more than 97 % market share , the reason is the high cost , coupled with good results after the breakdown of the drive. This kind of basic step angle of the motor 1.8 °/ step , half step back coupled with the drive to reduce the step angle of 0.9 °, coupled with sub-drive after its step angle can be broken up to 256 -fold (0.007 °/ micro step . Due to friction and manufacturing precision and other reasons , the actual control accuracy is slightly lower . Same stepper motors can be equipped with different segments of the drive to change the precision and effectiveness.3. selection methodStepper motor and drive selection methods :Determine how much torque is required : static torque stepper motor is to choose one of the main parameters. Load is large, requires the use of high torque motor. Indicators big moment , the motor appearance is also large.Determine motor speed : high speed requirements , should be selected phase current is larger , smaller inductor motors to increase power input. And select the drive when using higher supply voltages.Select motor installation specifications : as 57,86,110 , the main requirements for the moment .Determine the precision positioning requirements and vibration aspects of the case : to determine whether the required segments, the number of segments required .According to the motor current , supply voltage breakdown and select the drive .4. Basic PrinciplesWorksThe rotor is a permanent magnet motor typically , when a current flows through the stator windings , the stator winding generates a magnetic field vector . The rotating magnetic field to drive the rotor at an angle such that the magnetic field of the stator is consistent with a direction of the magnetic field of the rotor. When the stator magnetic field vector rotation angle. As the rotors turn a field angle . Each input an electrical pulse , the motor rotation angle forward. The number of pulses proportional to the angular displacement of the output and its input , the pulse frequency is proportional to the rotational speed . Change the order of the winding is energized , the motor will reverse. Therefore, the number of pulses can be used to control power-on sequence , frequency and motor windings to control each phase stepper motor rotation .Fever principleUsually see all kinds of motors , are all inside the core and windings . Windings resistance , power will produce loss , the loss is proportional to the square of the size of the resistance and current , and this is what we often say that the copper losses , if thecurrent is not a standard DC or sine wave , but also produce harmonic losses ; core has hysteresis eddy current effect , in the alternating magnetic field will produce losses , its size and materials , current, frequency , voltage dependent , called iron loss. Copper and iron losses are manifested in the form of heat , thus affecting the efficiency of the motor . Stepper motors are generally pursue positioning accuracy and torque output , efficiency is relatively low, the current is generally relatively large, and the high harmonic components , the frequency of the alternating current with the speed of change, thus stepping motor widespread fever cases and situations than the general severe AC motor .5. major tectonicStepping motor is also called a stepper , which uses the principle of electromagnetic , mechanical energy is converted to electrical energy , People as early as the 1920s began to use this motor . As embedded systems ( such as printers, disk drives , toys, wipers, pager vibration , mechanical arm and video recorders , etc. of the increasingly popular use of the stepper motor also began surge. Whether in industrial, military , medical, automotive or entertainment industry , as long as a piece of the object needs to be moved from one location to another , the stepper motor will certainly come in handy. Stepper motors have many shapes and sizes, but regardless of how the shape and size , they can be classified into two categories : a variable reluctance stepper motors and permanent magnetstepper motors.A stepper motor is wound on the motor fixing part - the stator coils driven alveolar . Typically , a ring-shaped metal wire called a solenoid winding , and in the motor , the teeth around the winding wire is called the coil or phase .6. index termsStatic index terms1, number of phases : produce different on pole N, S magnetic excitation coil pairs. Common m said .2, Beats: cyclical changes in the magnetic field required to complete a number of pulses or conductive state with n, or refer to the motor turned a pitch angle required number of pulses to four-phase motor, for example , there are four ways with four -run shot that AB-BC-CD-DA-AB, four-phase eight-shot operation That way A-AB-B-BC-C-CD-D-DA-A. 3, step angle : corresponds to a pulse signal , the angular displacement of the rotor turn is repre sented by θ. θ = 360 degrees / ( number of rotor teeth * run sh ot to the conventional two , four-phase , the rotor teeth 50 teeth motor, for example . Four beats running step angle is θ = 360 degrees / ( 50 * 4 = 1.8 degrees ( commonly known as the full step , eight-shot operation step angle of θ = 360 degrees / ( 50 * 8 = 0.9 degrees ( commonly known as half-step .4, the detent torque : motor is not energized in the state itself locked rotor torque ( harmonics and mechanical error by the magnetic field caused by the tooth .5, static torque : motor at rated static electricity effect, the motor doesnot rotates when the motor shaft locking torque. This moment is a measure of the volume of the standard motor , regardless of the driving voltage and driving power supply. Although static torque is proportional to the electromagnetic excitation ampere-turns , and set the air gap between the rotor teeth related, but over the use of the air gap decreases , increasing the excitation ampere-turns to increase the static torque is not desirable, this will cause motor heating and mechanical noise.Dynamic Indicators term1,step angle accuracy: stepper motor turned every error between the actual value and the theoretical value of a step angle . Expressed as a percentage : error / step angle *100 %. Different running different beats its value , when the four -run shot in the5% ,eight shot should run less than 15 %.2, step : the number of steps the motor running operation does not mean that the theoretical number of steps . Called out of step .3, the offset angle: rotor stator teeth tooth axis shift axis angle , the motor is running there must be offset angle , angle error generated by the imbalance , driven by subdivision can not be solved .4, he maximum no-load starting frequency : motor in the form of a drive voltage and rated current, in the case without the load, the maximum frequency can directly start .5, the operating frequency of the maximum load : the motor in the form of a drive voltage and rated current, the maximum speed of the motor with no load frequency .6, running torque characteristics : Measured motor running undercertain test conditions the output torque versus frequency curve is called the running torque-frequency characteristic , which is the motor of many dynamic curve of the most important , but also the fundamental basis for the motor selection.Other features include inertia frequency characteristics, starting frequency characteristics. Once the motor is selected, the static torque of the motor is determined , and dynamic moment is not the case , the dynamic torque motor depends on the average current ( rather than static current motor is running , the average current , the greater the motor output torque that the motor frequency characteristics of the harder . For the average current, the drive voltage to maximize the use of small high-current inductor motor .7, the resonance point of the motor : stepper motor has a fixed resonance region , two , four-phase Induction resonance zone is generally between 180-250pps ( step angleof 1.8 degrees , or about 400pps ( step angle 0.9 degrees , the higher the motor drive voltage , motor current increases, the lighter the load , motor size smaller, the upward shift resonance region , and vice versa , so that the motor output torque is large , and the entire system without losing step noise reduction , general working point should shift more resonance region .8, motor reversing control : the timing of when the motor windings are energized for the forward , the timing is energized when AB-BC-CD-DA or ( DA-CD-BC-AB or( when inverted.7. features characteristicThe main features1, the general accuracy of the stepper motor step angle of 3-5 % , and does not accumulate.2, the appearance of the stepper motor maximum temperature allowed . First, make a stepper motor temperature magnetic motor demagnetization ,Resulting in the loss of torque down even further , so the maximum temperature of the motor should be allowed depending on the appearance of magnetic motor demagnetization points ; generally speaking, magnetic demagnetization points above 130 degrees Celsius , and some even as high as 200 degrees Celsius above , so the stepper motor surface temperature at 80-90 degrees Celsius completely normal .3, stepper motor torque will increase with the speed of decline .When the stepping motor rotates , the inductance of the motor windings of each phase will form a counter electromotive force ; the higher the frequency, the greater the back EMF . In its role, the motor with frequency ( or speed increases the phase current is reduced , resulting in decreased torque .4, the stepper motor can operate normally at low , but if more than a certain speed will not start , accompanied by howling.Stepper motor has a technical parameter : load starting frequency , ie stepper motor under no-load conditions to start the normal pulse frequency , if the pulse frequency is higher than this value, the motor does not start properly , you may lose steps or stall . Under a load , the starting frequency should be lower . If you want the motor to achieve high-speed rotation , the pulse frequency should speed up the process ,which starts at lower frequencies , and then rise to the hope that at a certain acceleration frequency ( motor speed rise from low speed . Stepper motor with its remarkable features in the era of digital manufacturing plays a significant purpose. Along with improving the different development of digital technology and the technology itself, stepper motor , stepper motors will be applied in more fields .Key FeaturesA stepping motor can be operated must be added before the drive , the drive signal is a pulse signal to be no pulse when the stepping motor is stationary, if the addition of a suitable pulse signal will at a certain angle ( called a step angle is rotated. Rotational speed and the pulse frequency is proportional to .2, phase stepper motor step angle of 7.5 degrees, 360 degrees around , you need to complete the 48 pulses .3, stepper motor with instant start and stop the rapid superior characteristics .4, change the order of the pulse , you can easily change the direction of rotation .Therefore , printers , plotters , robotics and other equipment to the stepper motor driven core .8. speed methodStepper motor pulse signal is converted to angular displacement or linear displacement .First, the overload is good. Its speed independent of load size , unlikeordinary motor when the load increase rate decline occurs when using the stepper motor speed and position , there are stringent requirements.The second is easy to control. Stepper motors are "steps" as a unit rotation , digital features more obvious .Third, the whole structure is simple . Traditional mechanical speed and position control structure is complicated , difficult to adjust after using stepper motors , which makes it simple and compact structure . Motor rotation speed is converted into a voltage , and passed as a feedback signal to the input terminal . Tacho is an auxiliary motor , the motor is installed at the end of the ordinary speed DC motor , the voltage generated by the motor speed feedback to the DC power supply, DC motor speed control to achieve the purpose .9. function module designThis module can be divided into the following three parts:· SCM system : control of stepper motors ;· Peripheral circuits : PIC microcontroller interface circuit and stepper motors ;· PIC procedure : Write SCM stepper electric power machine interface program to achieve output of the triangular wave signal.( 1 stepper motor and microcontroller interface .SCM is the excellent performance of the control processor, stepper motor control , interface components must have the following features.① voltage isolation .SCM work at 5V, while the stepper motor is working in dozens of V, or even higher. Once the voltage to the microcontroller series stepper motor , it will damage the microcontroller ; signals would interfere with chip stepper motor , the system may also lead to errors in the work , so the interface device must have isolation .② messaging functions.Interface components should be able to pass information to the microcontroller stepper motor control circuit generates control information needed work , corresponding to different ways of working, interface components should be able to produce a corresponding job control waveform.③ produce different frequencies required .To the stepping motor at different speeds to suit different purposes , interface components should produce different operating frequencies . ( 2 V oltage Isolation interface.Isolation voltage isolation interface dedicated to the low-pressure part of the microcontroller and the stepper motor drive circuit high-voltage part , to ensure that they work properly.V oltage pulse transformer isolation interface or optical isolator is basically the use of optical isolators. Microcontroller output signal can be sent directly to the TTL gate or base of the transistor , and then driven by the transistor optocoupler devices emitting diodes.Light -emitting diodes on the opto-coupler devices inside the photodiode , converted into electrical signals , go drive a stepper motor power amplifier circuit , current amplification interface is a stepper motoramplifier circuit preamplifier circuit . Its role is to optical isolator output signal current amplification in order to provide enough power amplifier circuit drive current .( 3 Work interface and frequency generator .MCU controlled stepper motor requires the input and output interfaces for controlling stepper motors using three I / 0 lines, this time, the microcontroller I / O port RA0, RAI, RA2 control three-phase stepping motor .10. advantages and defectsAdvantage1, the angle of rotation of the motor is proportional to the number of pulses ;2, when the motor is stopped with a maximum torque ( when winding excitation time ;3, the accuracy of each step in the three percent to five percent , but the error will not accumulate to the next step and thus a better position accuracy and repeatability movement ;4, excellent response from the stop and reverse ;5, since there is no brush , high reliability, and therefore the life of the motor depends only on bearing life ;6, only the response of the motor is determined by the digital input pulse , which can be open-loop control, which makes the structure of the motor can be relatively simple and cost control ;7, only the load can be connected directly to a very low speed synchronous rotation on the shaft of the motor ;8, since the speed is proportional to the pulse frequency , and thus a relatively wide speed range.Defect1, if not properly controlled prone resonance ;2, the high speed operation is difficult ;3, it is difficult to obtain a large torque ;4, there is no advantage, low energy efficiency in terms of volume and weight ;5, more than the load will destroy the synchronization , will be issued when the high speed vibration and noise .11. drive methodStepper motors can be connected directly to the power frequency AC or DC power source to work , but must use a dedicated stepper motor driver , which occurs by the pulse control unit , power drive unit , the protection unit and so on. Stepper motor drive unit with direct coupling , can also be interpreted as a stepper motor controller microprocessor power connector.12. drive requirements1, can provide rapid current rise and fall times ,Current waveform as close as possible to make a rectangle .With a cut-off period for the release of the current flow loop to reducethe back electromotive force at both ends of the windings and accelerate the current decay .2, has a high rhyme power and efficiency.Stepper motor driver , which is a pulse signal into the control system of the angular displacement of the stepper motor , or : a control signal for each pulse issued by the stepper motor drive of a step angle of rotation . That frequency is proportional to the speed of the stepper motor pulse signal. So to control the frequency pulse signal , the speed of the motor can be accurately ; controlled stepper pulse number , you can pinpoint the motor . There are a lot of stepper motor drive , power requirements should be based on the actual reasonable choice drive.13. Major ApplicationsSelect the stepper motorThere are step angle stepping motor ( related to the number of phases , static torque , and the current composition of the three elements .Once identified three elements , the stepper motor model has determined.1, step angle selectionStep motor angle accuracy depends on the load requirements , the minimum resolution of the load ( equivalent conversion to the motor shaft , the number of angles ( including gear for each equivalent motor should go. Step motor angle should be equal to or less than this angle. Step angle stepping motor on the market are generally 0.36 °/0.72 °( five-phase motors , 0.9 degrees / 1.8 degrees ( two , four-phase motor , 1.5 degrees / 3 degrees ( three-phase motors and so on.2, static moment of choiceDynamic torque stepper motor is difficult to determine all of a sudden , we tend to first determine the static torque of the motor. The choice is based on static torque load on the motor work, and the inertia of the load and the load can be divided into two kinds of friction load . Single inertia load and a single load is not present in friction . When direct start ( generally low when the two loads are to be considered , the main consideration inertial load during acceleration start, constant run into just consider friction loads. Under normal circumstances, the static torque should be 2-3 times the load of friction is good, static torque Once selected, the machine base and be able to determine the length of the motor down ( geometry .3, the current selectionLike static torque motors , due to the different current parameters , their operating characteristics vary greatly, can be based on torque-frequency characteristic curve , determine the motor current . Application note points1, the stepper motor used in low-speed situations --- rpm less than 1000 rpm , ( 0.9 degrees 6666PPS, preferably using 1000-3000PPS (0.9 degrees between , can make it work here through deceleration devices, At this high electrical efficiency, low noise ;2, the stepper motor is best not to use the state of the whole step , whole step when the state of vibration ;3, due to historical reasons, only a nominal voltage of 12V 12V motors , the voltage value other than the motor drive voltage V value, drive selectdriving voltage according to ( suggestions : 57BYG DC 24V-36V, 86BYG DC 50V, 110BYG using higher than the DC 80V, of course, in addition to 12 volts 12V constant voltage driver can also use other external power supply, but to consider the temperature rise ;4, the moment of inertia of the load should choose a large frame size motors ;5, when compared with the high-speed motor or high inertia loads , generally do not start working speed , and the use of up- speed gradually , without losing a step motor , two noise can be reduced while improving the positioning accuracy is stopped ;6, high-precision, through mechanical reduction should improve motor speed , or high number of sub-drive to solve, 5 -phase motor can also be used , but the prices of its entire system more expensive , less manufacturer , which is eliminated argument is the layman ;7, the vibration motor in the region should not , should be resolved by changing the voltage , current, or add some damping ;8, motor 600PPS (0.9 degrees following work should be low current , high inductance , low voltage to drive ;9, after the first election should follow the principle of the drive motor option .步进电机步进电机是将电脉冲信号转变为角位移或线位移的开环控制元步进电机件。